Thinker-IL-LAB
Thinker is an imitation learning toolchain for humanoid robots. It provides an end-to-end pipeline from simulation data collection to real-robot deployment for the Walker TienKung Pro, Walker TienKung Dex, Walker S2 EDU, and Walker C1 EDU platforms.
Built on NVIDIA Isaac Sim and HuggingFace LeRobot.
GitHub Repository · LQX-Code-SH/Thinker-IL-LAB Get Started
Capabilities
| Capability | Description | Status |
|---|---|---|
| ROS simulation | High-fidelity Isaac Sim environment for teleoperation and data collection | Available |
| Teleoperation | Keyboard / space-mouse teleoperation with a unified sim-to-real interface | In progress |
| Data collection & conversion | HDF5 / LeRobot data collection, conversion, and cleaning | Available |
| Policy training | Imitation learning with LeRobot (ACT / Pi0.5) | Available |
| Real-robot deployment | Policy inference and robot control, including a warm-started inference server | Available |
| Supported robots | Walker TienKung Pro / Walker TienKung Dex / Walker S2 EDU / Walker C1 EDU | Released |
Gallery
Simulation preview
Walker TienKung Pro
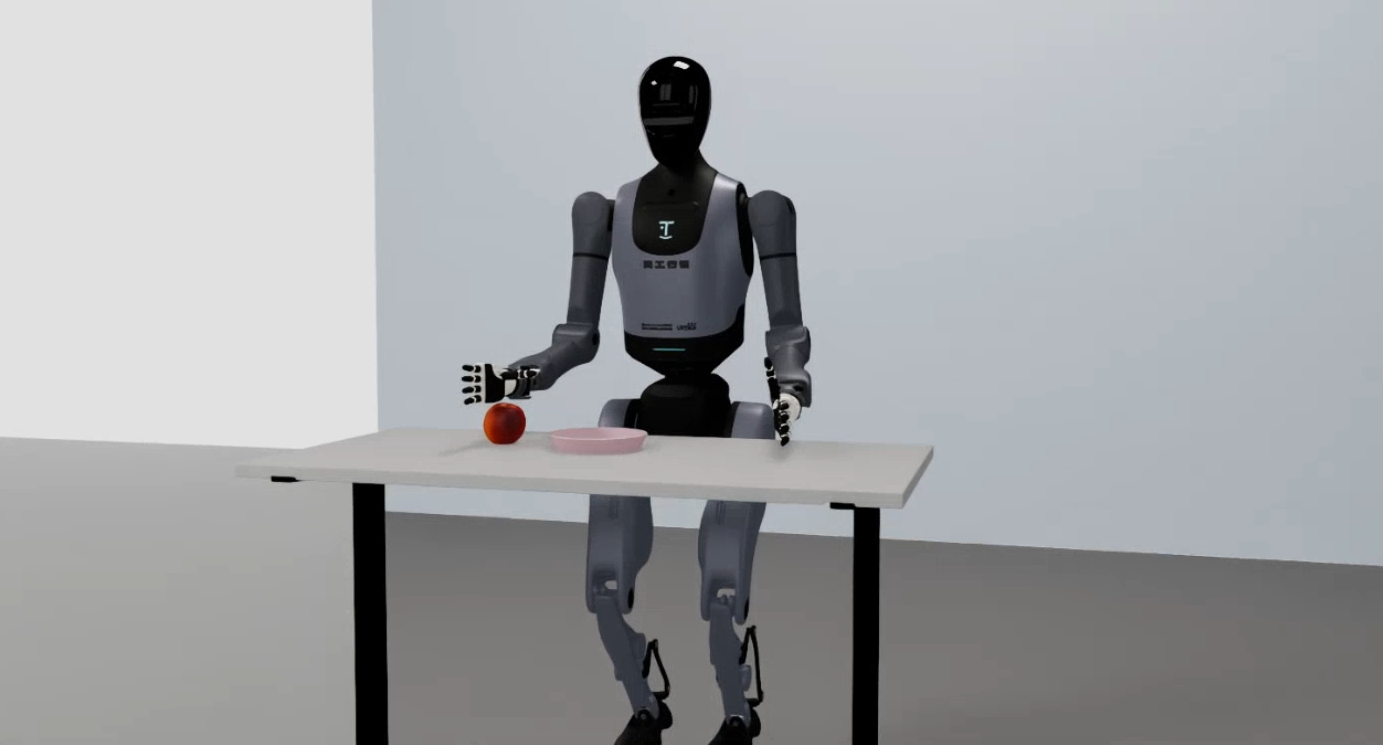
Walker TienKung Dex
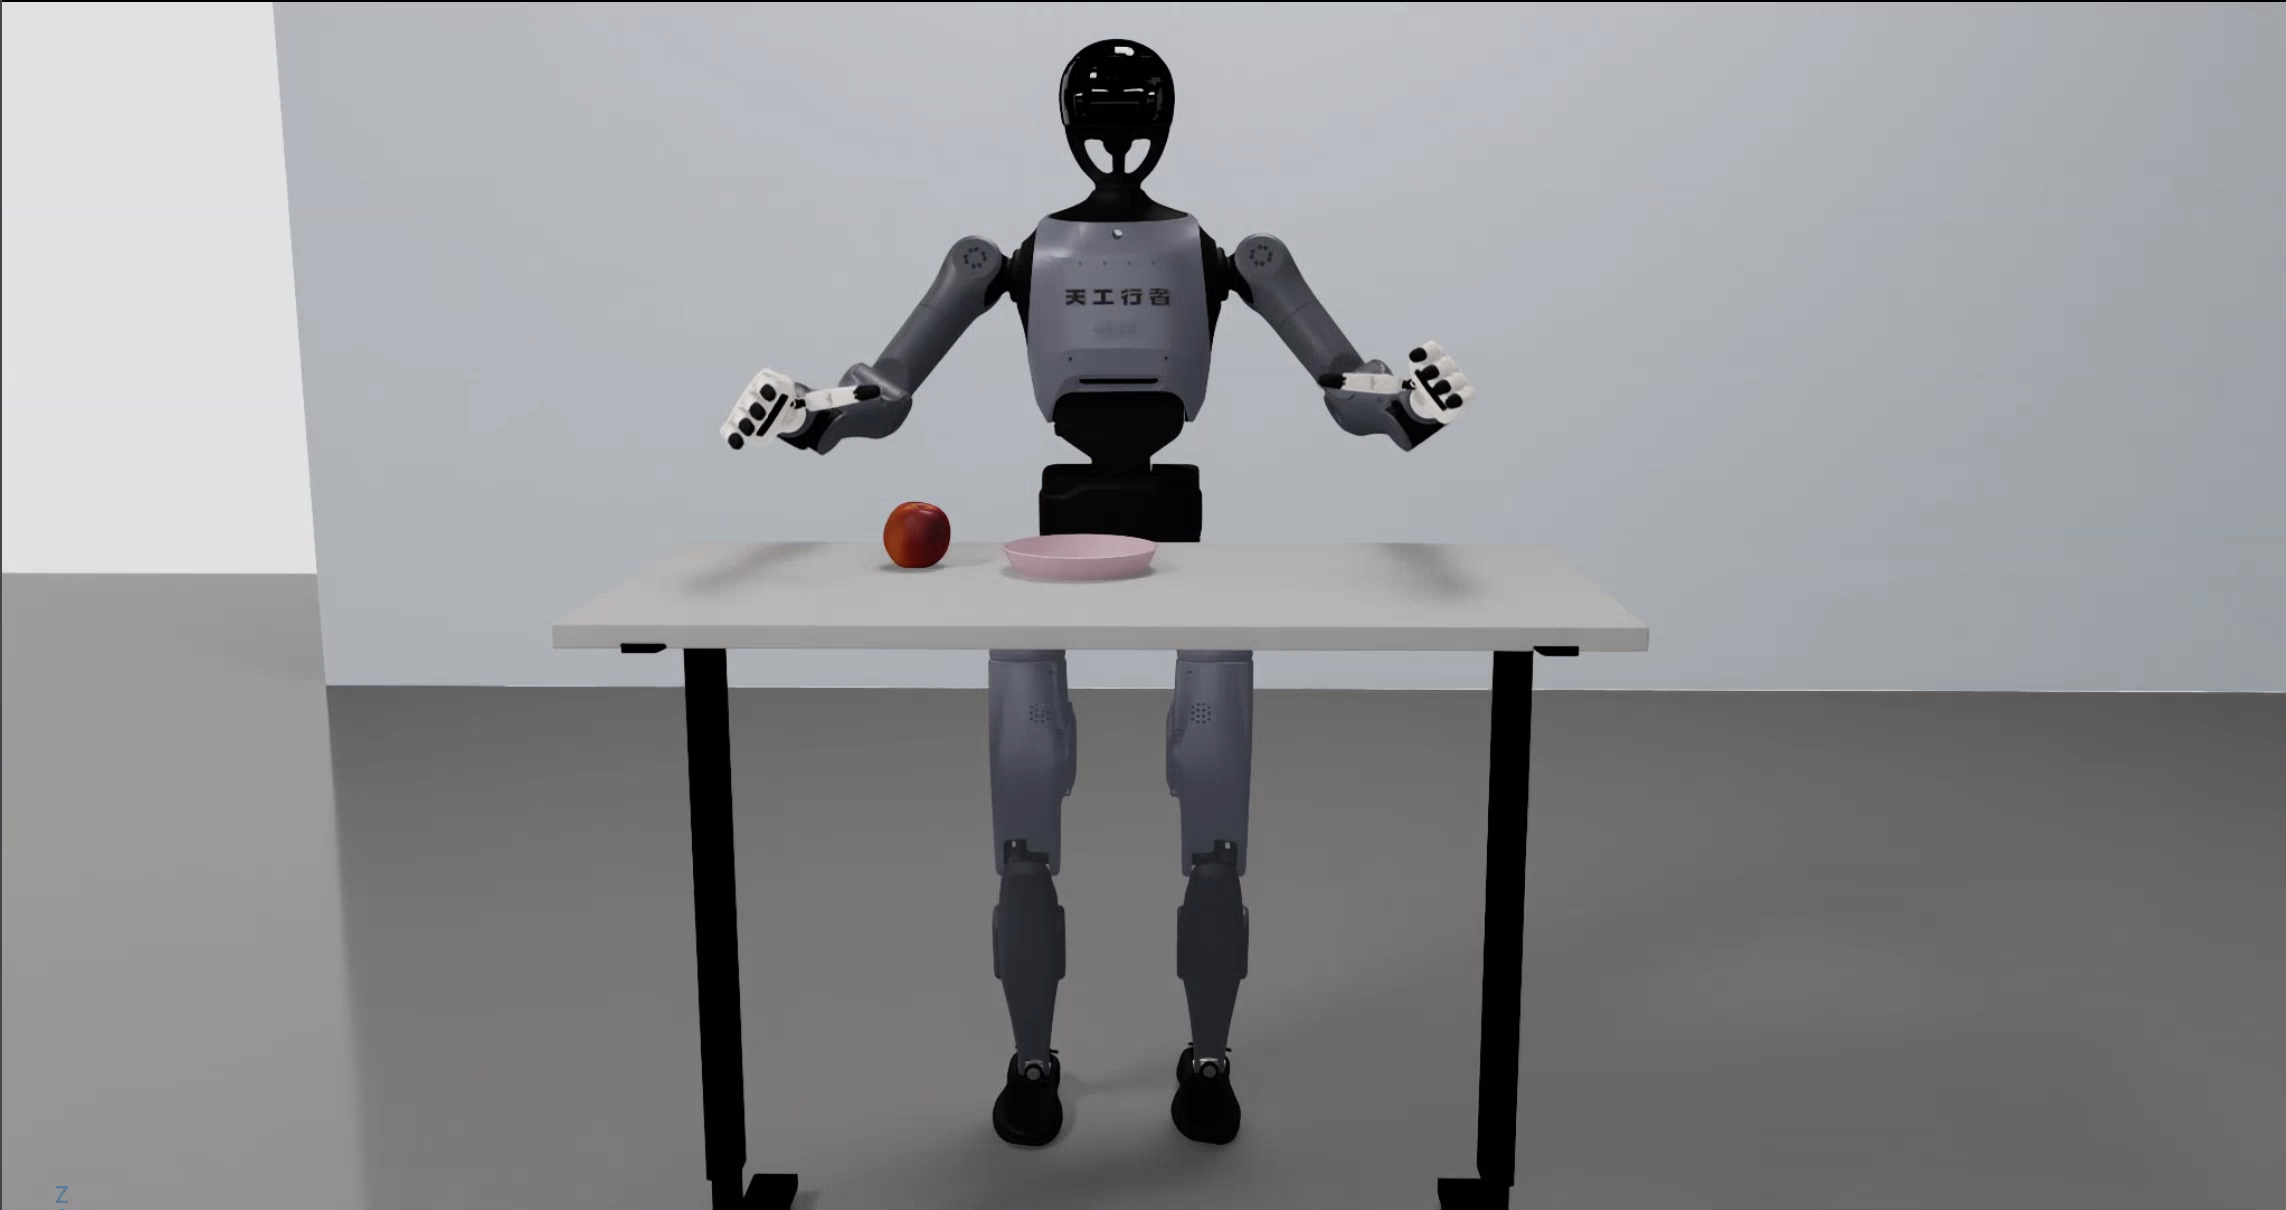
Walker S2 EDU
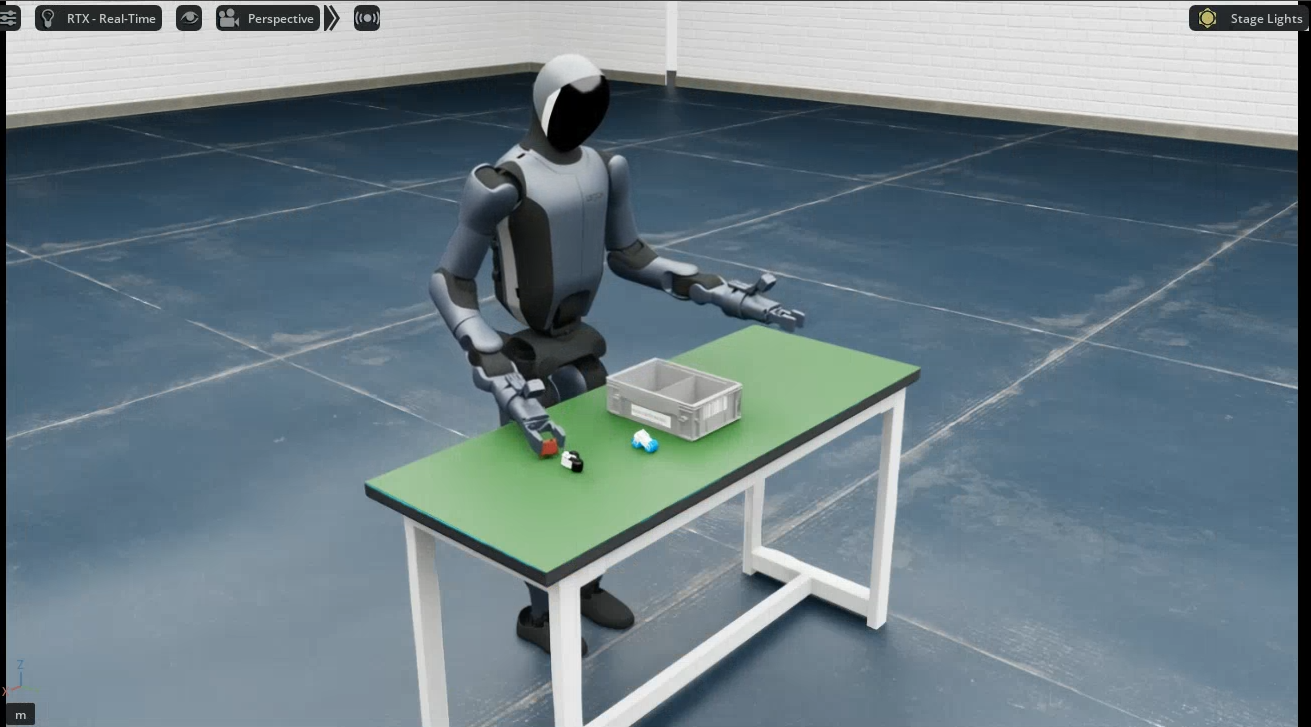
Walker C1 EDU
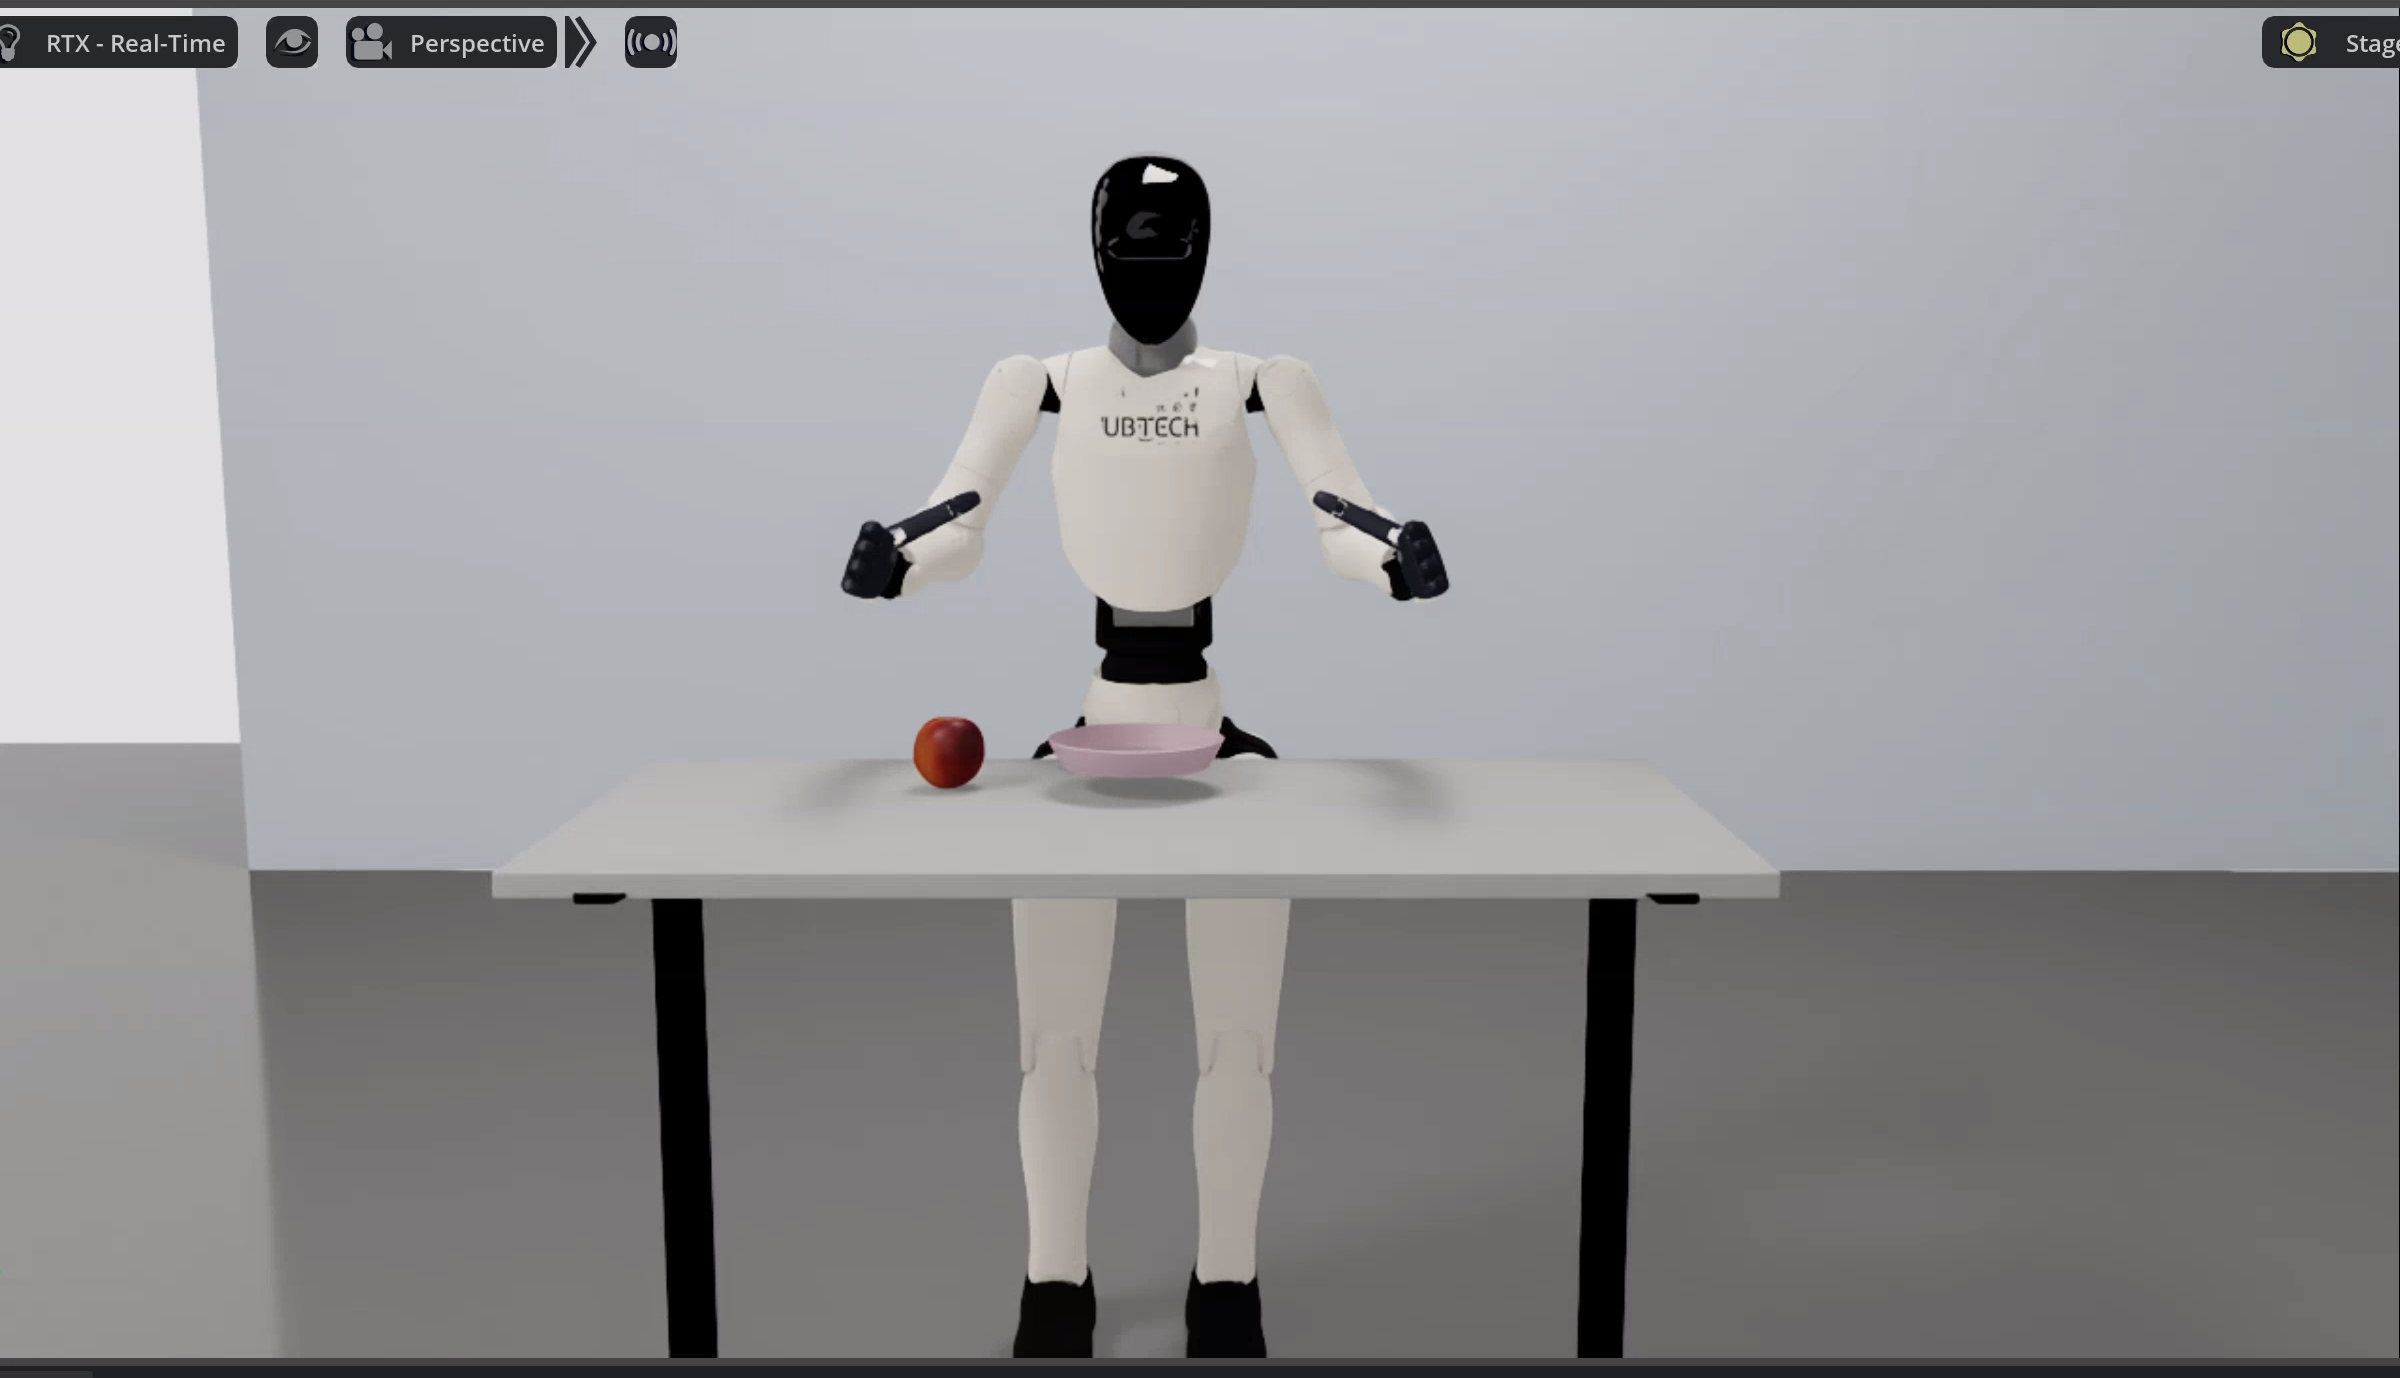
Deployment results
Walker TienKung Pro · Simulation
Walker TienKung Pro · Real robot
Walker S2 EDU · Simulation
Walker S2 EDU · Real robot
Walker TienKung Dex · Simulation
Walker TienKung Dex · Real robot
Walker C1 EDU · Simulation
Walker C1 EDU · Real robot
Application case
Walker S2 EDU · VLA pick-and-place
See Walker S2 EDU application case.
Architecture
The repository contains two sub-projects: ubt_sim (simulation platform) and ubt_IL (imitation learning platform).
┌──────────────────────────────────────────────────────────────────────────┐
│                          ubt_IL imitation learning                       │
│              data conversion ──► training ──► evaluation ──► deployment   │
└───────────▲───────────────┬──────────────────────▲──────────────┬────────┘
            │               │④ sim deployment       │              │⑤ real deployment
            │① data          ▼ (ROS bridge)          │② real data    │ (ROS bridge)
   ┌────────┴────────────────┐        ┌─────────────┴──────────────▼──────┐
   │      ubt_sim            │        │ Real robots:                      │
   │   (Isaac Sim container) │        │ Walker TienKung Pro /             │
   │                         │        │ Walker TienKung Dex /             │
   │                         │        │ Walker S2 EDU / Walker C1 EDU     │
   │                         │        │ ROS_DOMAIN_ID=0 direct network    │
   └─────────────────────────┘        └───────────────────────────────────┘
See Architecture Overview for details.
Start here
- Getting Started - Clone the repository, check requirements, and follow the end-to-end flow
- Simulation Platform - Isaac Sim, teleoperation, and data collection
- Imitation Learning Platform - Data conversion, training (ACT / Pi0.5), and evaluation
- Walker TienKung Pro - Simulation / conversion / training / deployment / ARM board deployment
- Walker TienKung Dex - Single-arm dexterous manipulation: simulation / training / real-robot deployment
- Walker S2 EDU - Simulation / conversion / training / deployment / inference server
- Walker C1 EDU - Dual-arm dexterous manipulation: simulation / training / real-robot deployment
Acknowledgements
This project builds on the following open-source projects:
- NVIDIA Isaac Sim - High-fidelity robotics simulation
- HuggingFace LeRobot - Imitation learning framework (ACT, data format, training and inference tools)
- Thinker Studio - Thinker teleoperation data collection platform
- Thinker Cosmos Open Source Community - Thinker open-source community
License
Apache-2.0