Walker C1 EDU Real-Robot Workflow: Collect -> Convert -> Train -> Evaluate -> Deploy¶
Robot: Walker C1 EDU Data source: real-robot teleoperation/scripted collection (Thinker Studio or
ubt_sim/teleoperation/control/walker_c1) Code:ubt_IL/scripts/{convert,train,eval,deploy}/walker_c1/
Simulation and the real robot share the same ROS 2 interfaces (mc_task_msgs / mc_state_msgs / sensor_msgs/Image) and are isolated by ROS_DOMAIN_ID. The policy deployment path sends only 26 dimensions (both arms + both hands) or 13 dimensions (right arm + right hand); the head/waist/legs hold their current positions.
✅ Verified on hardware (Nov 2026): the full loop works with 13D = right arm 7 + right hand 6 (
ROBOT_MODEL=walker_c1_13d, 30 fps, head camerahead_stereo_left/color/raw640×512): datasetwalker_c1_real_13d_1RGB(34 episodes / 11,406 frames) -> modelwalker_c1_real_13d_act_1RGB-> real-robot deployment.
Real robot ROS 2 ──► ubt_sim/teleoperation/control/walker_c1 (collection) ──► HDF5
                                                                             │
Container: convert.sh → train.sh → eval_policy.py → robot_ready.sh + rollout.sh
                                                                             │
LeRobot (3.12) ──ZMQ 5661/5662──► ros2_walker_c1_bridge.py (3.10) ──► real robot
Contents¶
- 0. Workflow overview
- 1. Real-robot prerequisites
- 2. Real-robot collection
- 3. Start the container
- 4. Data conversion (HDF5 -> LeRobot)
- 4.1 Conversion command
- 4.2 Data visualization
- 5. Training and evaluation
- 6. Deployment
- 7. FAQ
0. Workflow overview¶
| Stage | Location | Command |
|---|---|---|
| Switch SDK control | Operator machine / container | bash scripts/deploy/walker_c1/sdk_mode.sh half_sdk |
| Real-robot collection | Operator machine / ubt_sim container | teleoperation/control/walker_c1/save_data.sh |
| Container | Operator machine | cd ubt_IL/docker && bash run.sh start && bash run.sh bash |
| Conversion | Container | scripts/convert/walker_c1/convert.sh |
| Training | Container (GPU) | scripts/train/walker_c1/train.sh |
| Evaluation | Container | scripts/eval/eval_policy.py |
| Deployment | Container (robot side) | robot_ready.sh + rollout.sh |
1. Real-robot prerequisites¶
- Switch to SDK control (half_sdk required): C1 arms accept ROS 2 joint commands only in
workMode=develop+developModeState=HalfSdkActive(normalignores commands;full_sdkhands over whole-body balance and is not used for VLA). The deployment script performs the full sequence (enter developer mode → legs STAND → half_sdk) over SSH in the robot's developer container (ubt@192.168.11.3:2222):
bash /ubt_IL/scripts/deploy/walker_c1/sdk_mode.sh status     # work mode / motion permission / legs / e-stop
bash /ubt_IL/scripts/deploy/walker_c1/sdk_mode.sh check      # validate only (0 = deployable)
bash /ubt_IL/scripts/deploy/walker_c1/sdk_mode.sh half_sdk   # switch
bash /ubt_IL/scripts/deploy/walker_c1/sdk_mode.sh normal     # restore normal
rollout.sh / robot_ready.sh / robot_home.sh / inference_server.sh include the guard and refuse to run outside half_sdk (on hardware set WALKER_C1_REAL=1 or SDK_GUARD=1; simulation uses the default SDK_GUARD=auto and skips the check).
-
ROS domain: the real robot defaults to
ROS_DOMAIN_ID=0; simulation and real deployment must use the same value. Set both to146when isolation is needed. -
DDS: Thor (C1 onboard compute) must use the same RMW as the main control stack — the robot stack uses
rmw_cyclonedds_cpp+CYCLONEDDS_URI(bound tomgbe2_0, local192.168.11.3).docker/run.shinjects the same environment and mountsdocker/cyclonedds_thor.xml(CYCLONEDDS_URI=file:///opt/cyclonedds_thor.xml), so no manual setup is needed. Two field-tested caveats when editing the config: -
<Interfaces>must be inside<General>(Humble's CycloneDDS 0.10+). Under<Domain>it reportsunknown elementand falls back to the default NIC. List onlymgbe2_0, notlo(not multicast). - Domain 0 has many participants; the default limit raises
Failed to find a free participant index for domain 0. The config setsParticipantIndex=noneandMaxAutoParticipantIndex=120.
For FastDDS (simulation/remote machines), set RMW_IMPLEMENTATION=rmw_fastrtps_cpp and add the local NIC IP (Thor 192.168.11.3, Walker peer 192.168.11.99) to the docker/fastdds_no_shm.xml whitelist.
- State self-check (inside the container, after
run.sh bash):
source /opt/ros/humble/setup.bash
source /ubt_IL/walker_s2/walker_sdk_ros2/install/setup.bash
export ROS_DOMAIN_ID=0
ros2 topic hz /mc/sdk/robot_state                                 # measured ≈ 460-490 Hz on Thor
ros2 topic hz /sensor/camera/head_stereo_left/color/raw           # shm_msgs/Image6m
ros2 topic info -v /mc/sdk/robot_command                          # should have subscribers (SDK control active)
The real-robot RobotState contains only 19 joints (14 arm + 2 head + 3 waist, no legs). The bridge selects the 14 arm joints by name, so it is unaffected; head/waist/legs are not part of the policy and are not commanded.
- Safety: place the robot in a safe position; use
DURATION=10for the first short validation; keep the emergency stop within reach.
2. Real-robot collection¶
# Inside the ubt_sim container (same domain as the robot; do not reuse simulation processes)
bash teleoperation/control/walker_c1/save_data.sh
bash teleoperation/control/walker_c1/save_data.sh --batch 20
The output matches simulation: ubt_sim/dataset/walker_c1/<epoch>/trajectory.hdf5 (15 Hz, 31 body joints + 6+6 hand channels, one RGB stream). You can also use the Thinker Studio teleoperation platform and export a LeRobot v3 dataset directly.
The collection side needs the real camera topics — C1 hardware does not publish /sensor/camera/head/color/raw; it provides:
| Topic | Type | Notes |
|---|---|---|
/sensor/camera/head_stereo_left/color/raw |
shm_msgs/Image6m |
Policy input: 1920×1536, yuv422 (UYVY), step=3840, fixed 6 MB |
~~/sensor/camera/head_stereo_left/color/compressed~~ |
sensor_msgs/CompressedImage |
No longer published after the onboard vision stack restart |
head_stereo_right / head_fisheye_left,right / mono_chin / wrist_left,right |
Same family | Other views |
Aspect ratio: native 1920×1536 (5:4). The collection side stores JPEG at half size (960×768, still 5:4). Training and deployment consistently use 640×512 (5:4, exactly 1/3 of 1920×1536) with no cropping and no aspect-ratio change.
Use WALKER_C1_CAMERA_TOPIC + WALKER_C1_CAMERA_MSG_TYPE for collection/deployment (the deployment script uses CAMERA_TOPIC / CAMERA_MSG_TYPE). Topics ending in /compressed are inferred as compressed images; everything else defaults to sensor_msgs/Image. The real shm_msgs/Image6m type must be specified explicitly, otherwise the subscription type does not match.
3. Start the container¶
Thor (L4T r38 / sm_110) is selected automatically by env.sh, which uses Dockerfile.thor (image lerobot-tienkung:humble-thor, based on the robot's ros2_ws:humble-dyn). Do not use the Orin Dockerfile.arm64 (r36 base + sm_87 wheels; it does not run on Thor).
run.sh check should include:
[OK] walker_c1 plugin: installed[OK] walker_c1 bridge: available[OK] walker ROS2 msgs: installed(mc_state_msgs/mc_task_msgs, sharing the workspace with walker_s2)[OK] torch: 2.9.0+cu130 | arch: ...,sm_110,... | kernel: ok[INFO] RMW: rmw_cyclonedds_cpp | CYCLONEDDS_URI=file:///opt/cyclonedds_thor.xml
4. Data conversion (HDF5 -> LeRobot)¶
4.1 Conversion command¶
Verified path: real-robot 13D (config configs/walker_c1_real_13d_1RGB.json, 13D = right arm 7 + right hand 6, head camera 640×512, 30 fps):
CONFIG=/ubt_IL/scripts/convert/walker_c1/configs/walker_c1_real_13d_1RGB.json \
SRC_ROOT=/ubt_IL/dataset/walker_c1 \
REPO_ID=walker_c1_real_13d_1RGB \
FPS=30 \
bash /ubt_IL/scripts/convert/walker_c1/convert.sh --overwrite
- If the data is still in
ubt_sim/dataset/walker_c1, omitSRC_ROOT(the script falls back automatically) or set it explicitly. - Real-robot recordings are 30 fps; keep the conversion
FPSequal to the dataset frame rate. UseRESAMPLE_FPSfor other rates. - For 26D real-robot data use
walker_c1_real_26d_1RGB.json(dual-arm task). - Real hand ranges were verified: right hand
thumb_swing ≤0.68 / thumb_mcp ≤0.82 / four fingers ≤0.85, all within deployment limits (0.96 / 1.04 / 1.57).
For simulation conversion see Simulation workflow · Data conversion.
4.2 Data visualization¶
HF_HUB_OFFLINE=1 lerobot-dataset-viz \
  --repo-id walker_c1_real_13d_1RGB \
  --episode-index 0 \
  --root /ubt_IL/dataset/walker_c1_real_13d_1RGB
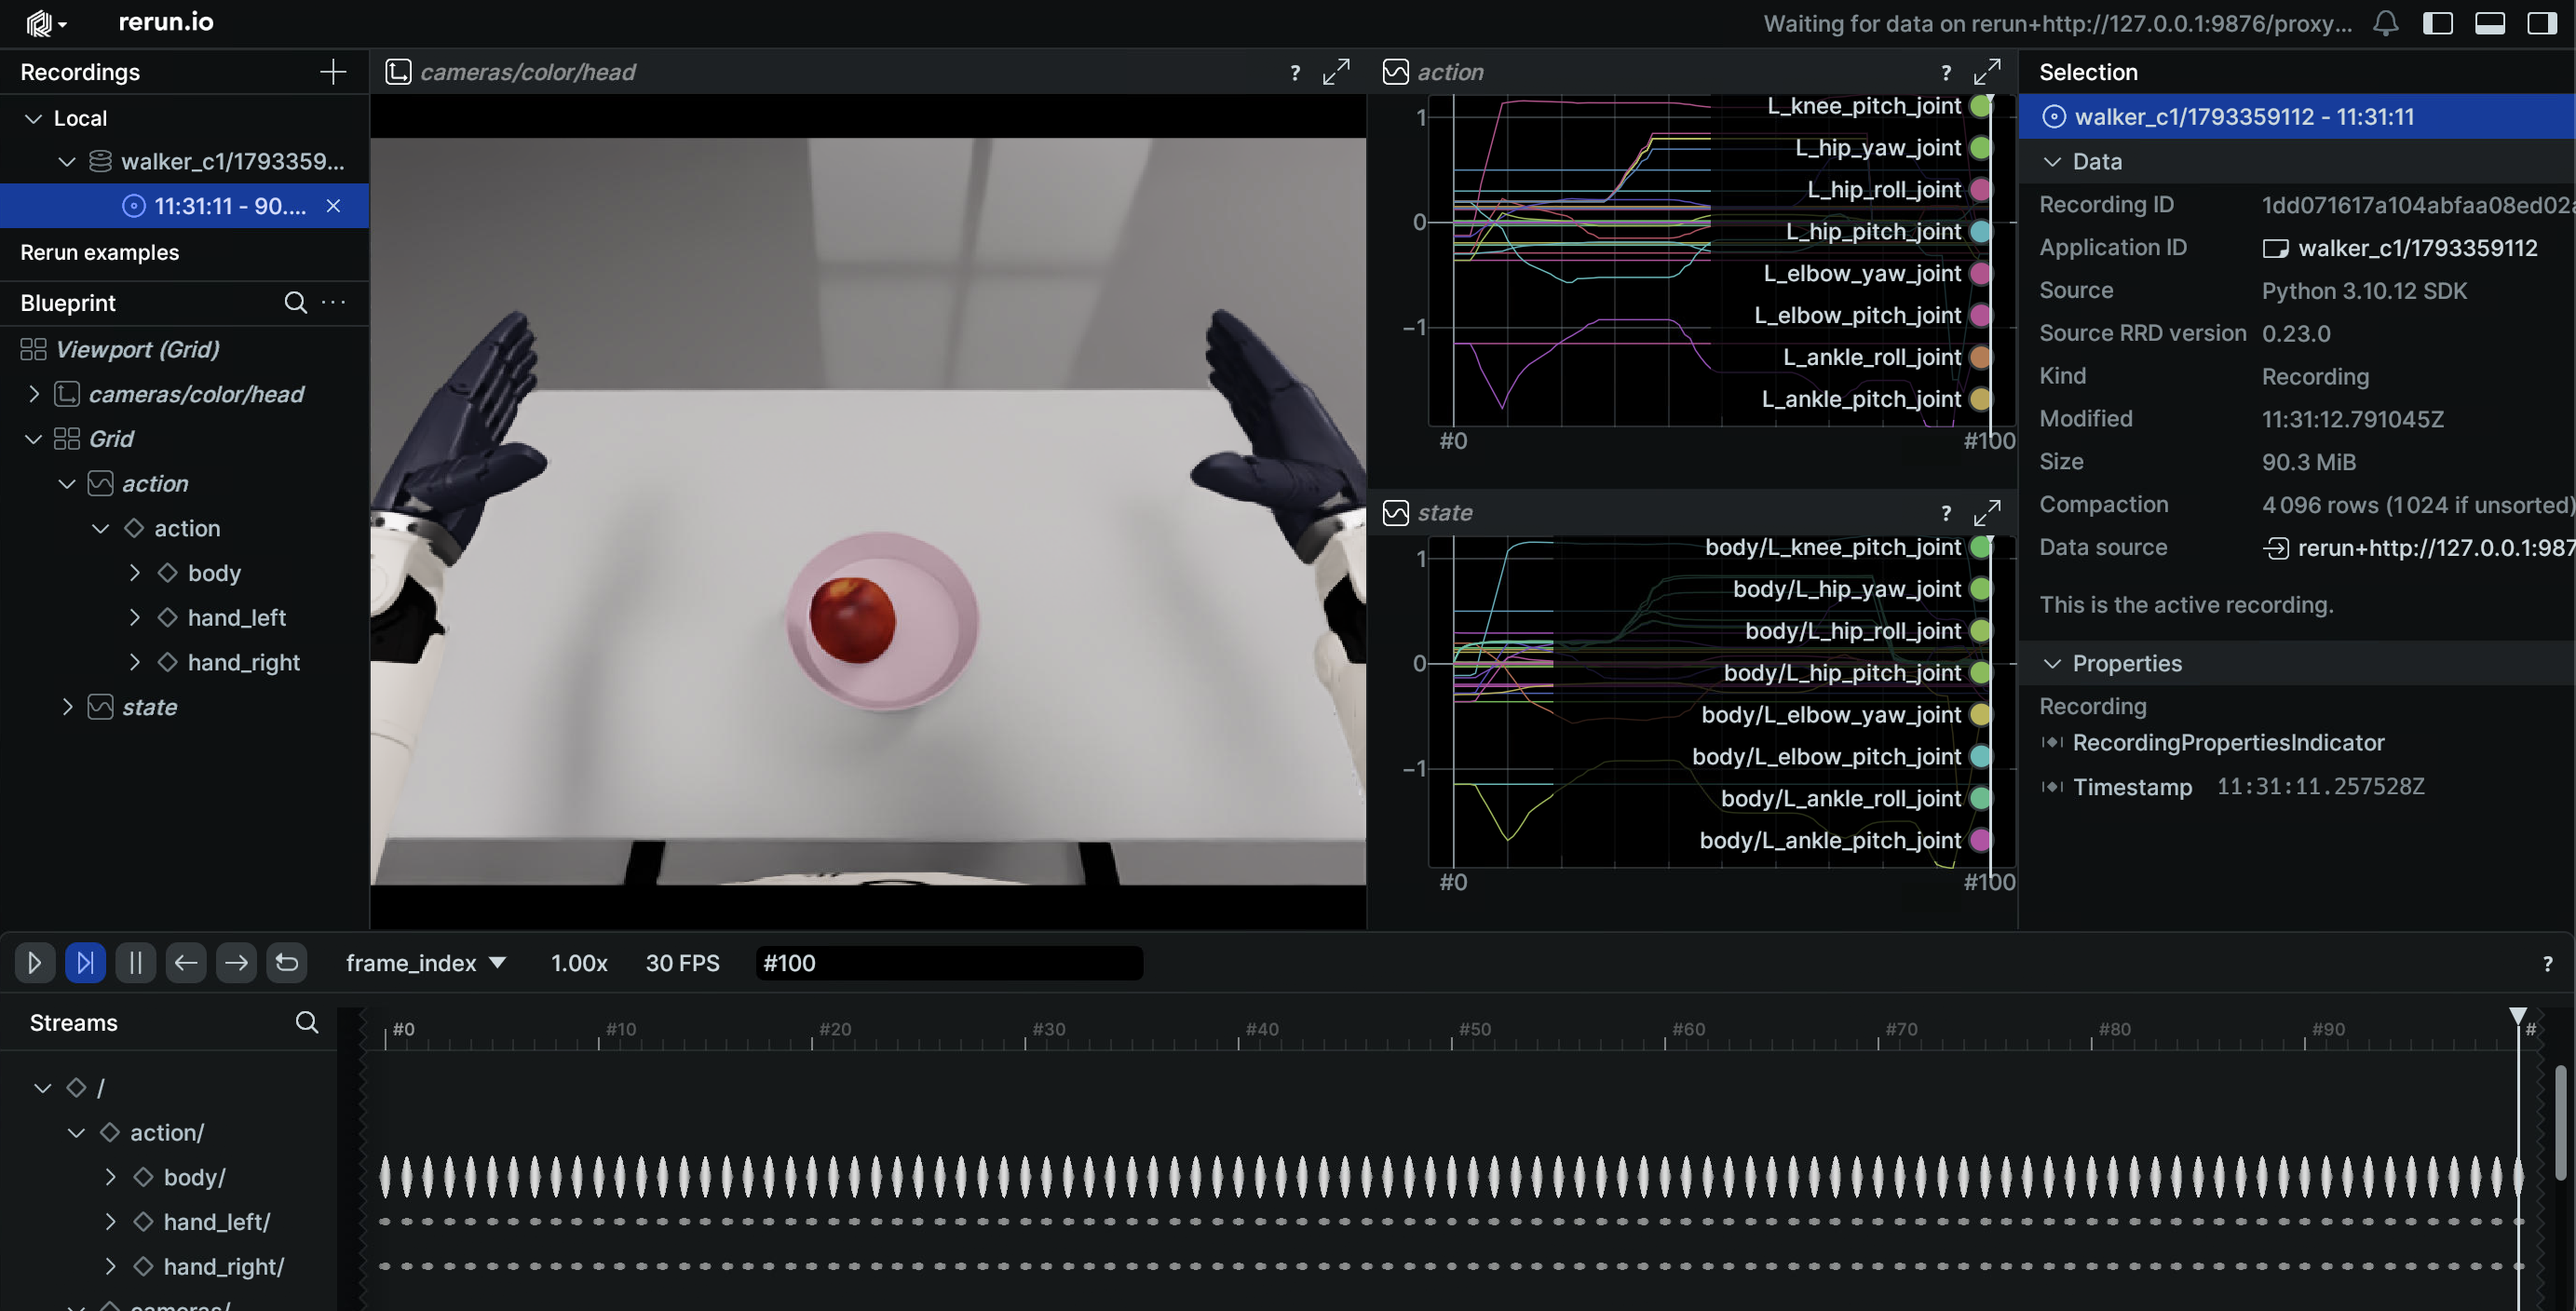
Check especially: image resolution (3×512×640), state/action dimension and order (13D = right arm 7 + right hand 6), hand range, and empty episodes.
5. Training and evaluation¶
Verified path: real-robot 13D training (config train_config_walker_c1_real_act_13d_1RGB.json, dataset walker_c1_real_13d_1RGB, output walker_c1_real_13d_act_1RGB):
CONFIG=/ubt_IL/scripts/train/walker_c1/configs/train_config_walker_c1_real_act_13d_1RGB.json \
OUTPUT_DIR=/ubt_IL/model/walker_c1_real_13d_act_1RGB \
bash /ubt_IL/scripts/train/walker_c1/train.sh
train.shdefaults to the simulation 26D config; real-robot training must setCONFIG=explicitly. When real lighting differs strongly from simulation,image_transformsis enabled by default in the config (color jitter / random affine).
Offline evaluation (real-robot dataset):
/lerobot/.venv/bin/python /ubt_IL/scripts/eval/eval_policy.py \
  --policy-path /ubt_IL/model/walker_c1_real_13d_act_1RGB/checkpoints/last/pretrained_model \
  --dataset-path /ubt_IL/dataset/walker_c1_real_13d_1RGB \
  --episodes 5 --inference-freq 1 --plot \
  --plot-dir /ubt_IL/scripts/eval/output/eval_walker_c1_real_13d_act \
  --output /ubt_IL/scripts/eval/output/eval_walker_c1_real_13d_act/results.json \
  --device cuda
With small real datasets, inspect per-dimension curves for plausibility (hand jitter, wrist overshoot) instead of relying only on the total MSE.
6. Deployment¶
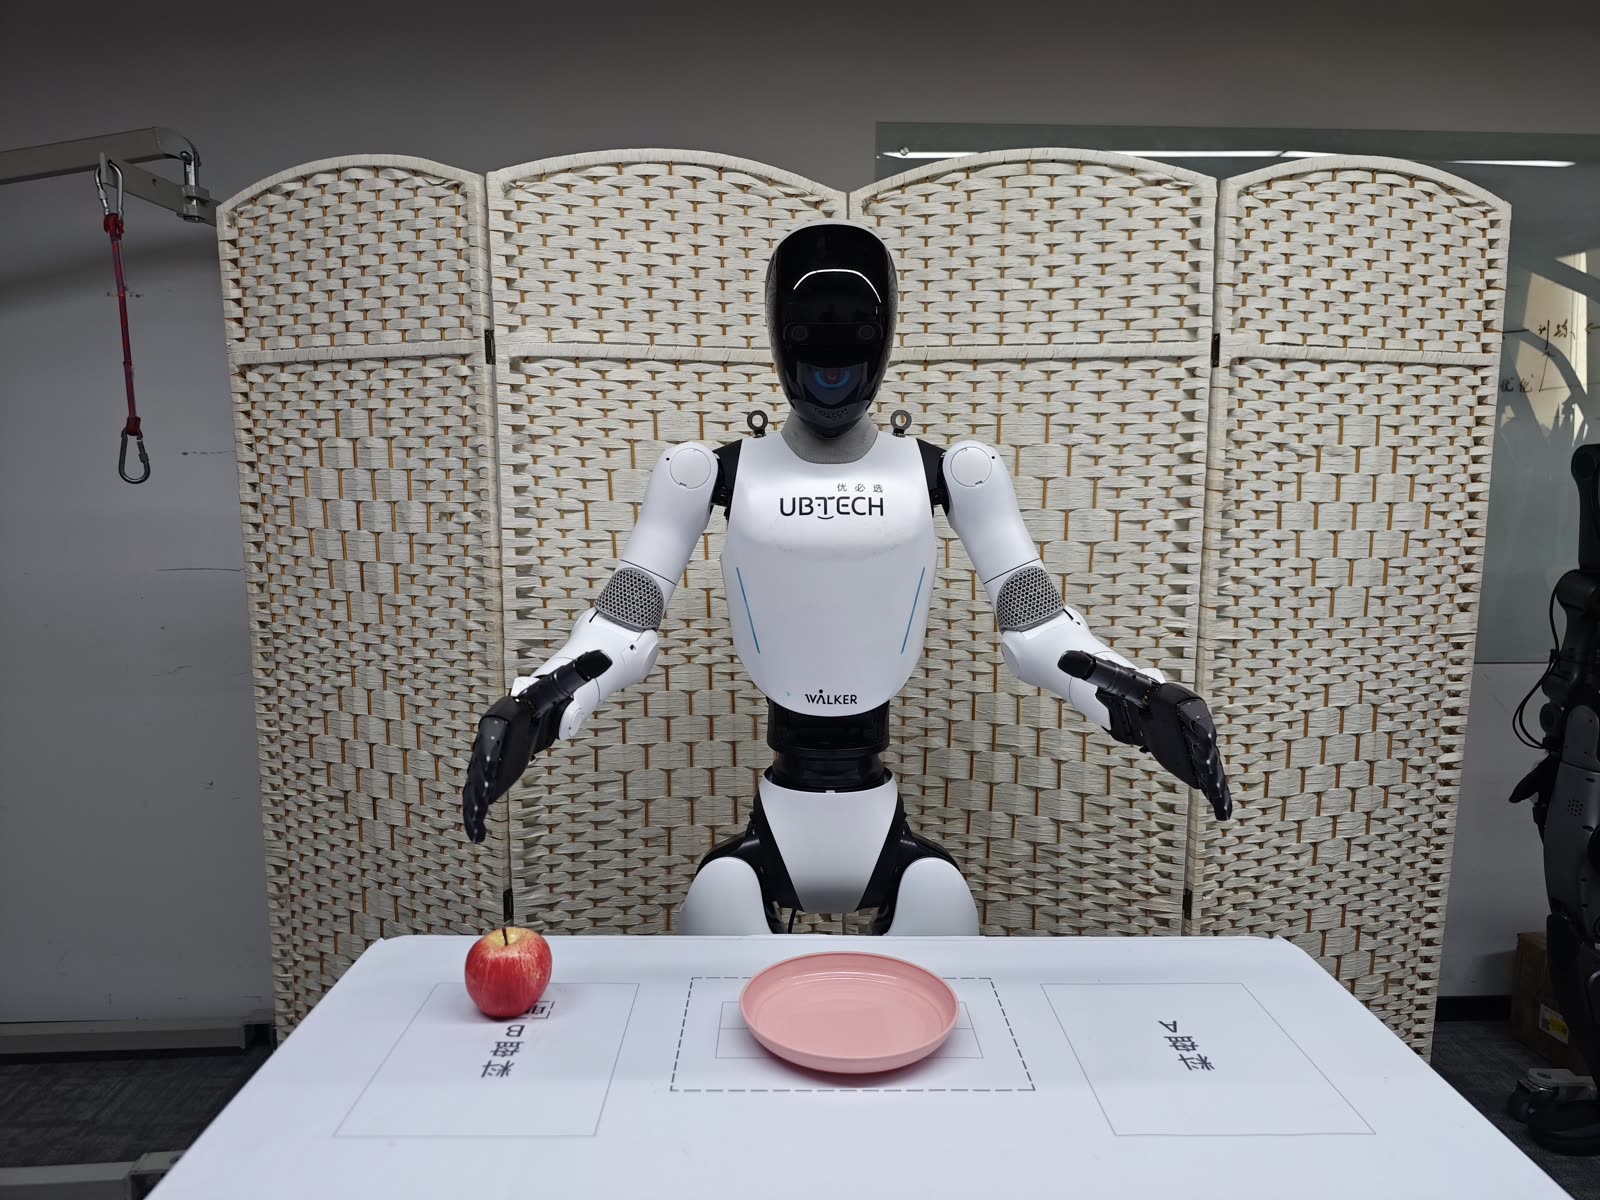
Real-robot deployment (on-site photo):
# ⓪ Switch to half_sdk (developer mode + half-body SDK; idempotent, only prints state if already ready)
bash /ubt_IL/scripts/deploy/walker_c1/sdk_mode.sh half_sdk
bash /ubt_IL/scripts/deploy/walker_c1/sdk_mode.sh check      # 0 = deployable

# ① Camera check (real: head_stereo_left/color/raw, shm_msgs/Image6m)
python3 /ubt_IL/scripts/deploy/walker_c1/preview_camera.py --once --save-frame /tmp/c1.jpg \
  --msg-type image6m --topic /sensor/camera/head_stereo_left/color/raw

# ② Move to the ready pose (dry-run first to inspect targets and stage durations)
bash /ubt_IL/scripts/deploy/walker_c1/robot_ready.sh --dry-run
bash /ubt_IL/scripts/deploy/walker_c1/robot_ready.sh

# ③ Single-episode rollout (WALKER_C1_REAL=1 enables the half_sdk guard; refuses outside half_sdk)
#    Verified path: real-robot 13D model (on hardware ROBOT_MODEL defaults to walker_c1_13d)
WALKER_C1_REAL=1 SDK_GUARD=1 \
POLICY_PATH=/ubt_IL/model/walker_c1_real_13d_act_1RGB/checkpoints/last/pretrained_model \
DURATION=10 FPS=30 RESET_MODE=task \
CAMERA_TOPIC=/sensor/camera/head_stereo_left/color/raw \
CAMERA_MSG_TYPE=shm_msgs/Image6m \
  bash /ubt_IL/scripts/deploy/walker_c1/rollout.sh

# ④ Return home (home = all 14 arm joints at 0, arms straight down, hands open)
bash /ubt_IL/scripts/deploy/walker_c1/robot_home.sh --dry-run
bash /ubt_IL/scripts/deploy/walker_c1/robot_home.sh

# ⑤ Optional warm-started inference server (see inference-server.md)
WALKER_C1_REAL=1 \
POLICY_PATH=/ubt_IL/model/walker_c1_real_13d_act_1RGB/checkpoints/last/pretrained_model \
  bash /ubt_IL/scripts/deploy/walker_c1/inference_server.sh
- Ready pose includes a head-down angle of
head_pitch=0.65 rad(37.2°): field tests show 0.50 only sees the table edge, while 0.65 covers the full table. Adjust with--head-pitch;--no-headleaves the head untouched. The three stages (raise shoulder → fold elbow → ready pose) default to ≥ 5 s each (15 s total + 0.5 s hold), and the log prints peak displacement and velocity (≈0.5 rad/s). - home is the exact reverse of the three ready stages (wrist/shoulder pitch to zero → unfold elbow → lower shoulder); measured final error max |pos| ≈ 0.02 rad. It moves only the arm and hand; head/waist/legs are untouched.
- Inference backend: prefer
act_async(default); serialsyncis for debugging only and must keep single-action smoothing (default 0.15 s; setting 0 triggers a warning). RESET_MODE: the real robot has no/sim/cmd_reset; usetask(pose only) ornone.max_relative_target:nullin the config JSON; set e.g.0.05rad/step when per-step limiting is needed.disable_torque_on_disconnect=true: smoothly return home on exit (2 s chunk).
Real-robot deployment demo:
See Real-robot deployment for the full guard, registry, and safety precheck details.
7. FAQ¶
| Symptom | Fix |
|---|---|
| Arm does not move at all | Run sdk_mode.sh check: is it develop + HalfSdkActive + standing? Then check whether /mc/sdk/robot_command has subscribers and whether ROS_DOMAIN_ID matches |
| Only the right hand moves | The left hand is all zeros in the data (task characteristic); the policy reproduces this, which is normal |
| Joint 4 direction/name mismatch | SDK docs call it elbow_roll, the URDF calls it elbow_pitch; the bridge tolerates aliases, but verify the sign on hardware |
| Sudden motion | Set max_relative_target; lower FPS; check hand limits |
| Camera artifacts / no image | Simulation sensor_msgs/Image encoding should be rgb8; real is shm_msgs/Image6m (UYVY); QoS must be BEST_EFFORT |
| Arm does not return after exit | disable_torque_on_disconnect was set false, or the bridge was killed externally |
| Inference service unreachable | Ports 5690/5691; check the state machine with inference_client.sh status |
Empty topic list / no /mc/* |
RMW mismatch: on hardware use rmw_cyclonedds_cpp + cyclonedds_thor.xml (see §1 item 3) |
Failed to find a free participant index |
CycloneDDS default participant limit is too low; use ParticipantIndex=none + MaxAutoParticipantIndex=120 |
| Camera topic missing / no frames | On hardware use CAMERA_TOPIC=.../head_stereo_left/color/raw + CAMERA_MSG_TYPE=shm_msgs/Image6m; green/purple colors mean UYVY is being decoded as YUYV |
torch.cuda.is_available() is False |
The container lacks NVIDIA_VISIBLE_DEVICES=all / NVIDIA_DRIVER_CAPABILITIES=all (run.sh start sets them) |