Walker TienKung Dex
Walker TienKung Dex is the single-arm dexterous manipulation variant of the TienKung series: a 7-DOF right arm plus a dexterous right hand, available with either the Inspire RH5DG2 (67 revolute joints) or BrainCo Revo2 (53 revolute joints) hand. The policy controls only the right arm and right hand; the left arm, waist, head, and legs are moved to the ready pose by robot_ready.sh and then held still.
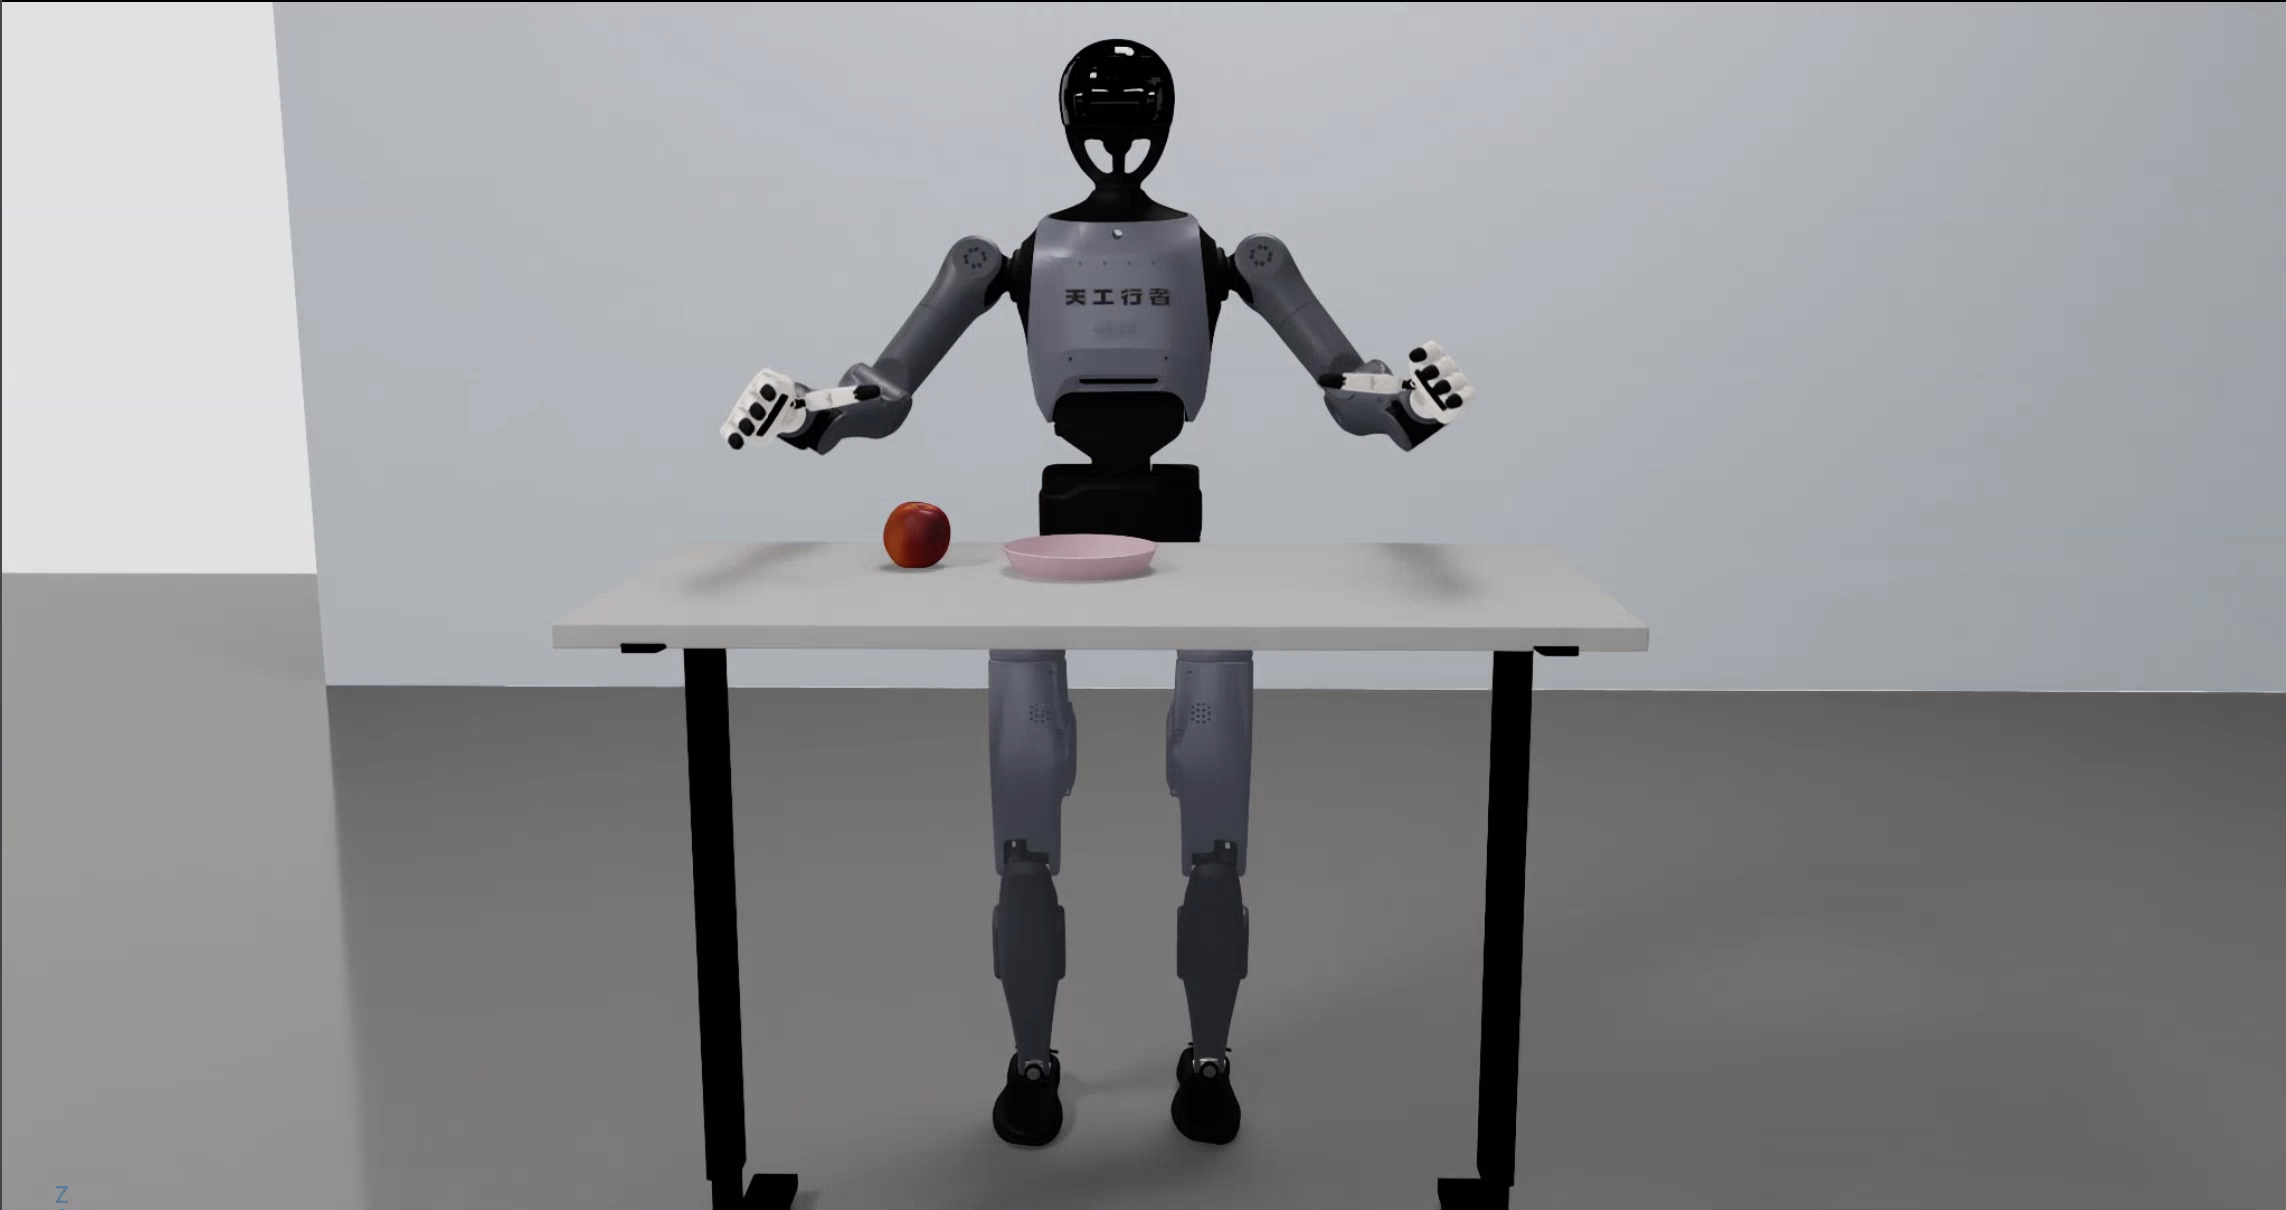
Specifications
| Item | Specification |
|---|---|
| Configuration | 7-DOF right arm + dexterous right hand (Inspire 13 channels / BrainCo 6 motors) |
| Dexterous hand | Inspire RH5DG2 (67 revolute) / BrainCo Revo2 (53 revolute) |
| Common training dimensions | 20D (right arm 7 + right hand 13, Inspire) / 13D (right arm 7 + right hand 6, BrainCo or Inspire r13) |
| Joints not controlled by the policy | Left arm / waist / head / legs (constant in the data; held at the ready pose) |
| LeRobot plugin | ubt_IL/tienkung_dex/lerobot_robot_tienkung_dex (robot type tienkung_dex, camera type dex_camera) |
| USD model | ubt_sim/assets/robots/tienkung_dex/usd/tienkung_dex_inspire.usd / tienkung_dex_brainco.usd |
| Camera | Head-mounted monocular RGB: /ob_camera_head/color/image_raw |
| Training resolution | Simulation / BrainCo real: 640×360 RGB; Inspire r13 real config: 1280×720 |
| ROS domain | ROS_DOMAIN_ID=0 by default (same domain as the real robot; set 146 on both sides to isolate) |
✅ Verified on hardware (Nov 2026): the full real-robot training and deployment loop has been validated with both Inspire and BrainCo hands. Verified dataset:
tienkung_dex_real_pick_apple_brainco_13d(32 episodes / 16,956 frames / 30 fps, 13D = right arm 7 + BrainCo hand 6).
Action space (three JOINT_CONFIG variants)
JOINT_CONFIG |
Dimension | Hand | Policy-side hand representation |
|---|---|---|---|
tienkung_dex_20 |
20D = right arm 7 + right hand 13 | Inspire | 13 joint angles in rad |
tienkung_dex_brainco_13 |
13D = right arm 7 + right hand 6 | BrainCo | 6 closure values in 0~1 |
tienkung_dex_inspire_13 |
13D = right arm 7 + right hand 6 | Inspire | 6 normalized values in 0~1, expanded by Bridge2 into 13 angle codes |
Simulation tasks
| Task ID | Hand | Joints | Config |
|---|---|---|---|
UBTSim-TienkungDex-Parlor-v0 |
Inspire RH5DG2 | 67 | config/tienkung_dex/parlor.yaml |
UBTSim-TienkungDex-Brainco-Parlor-v0 |
BrainCo Revo2 | 53 | config/tienkung_dex/brainco_parlor.yaml |
Documentation
Platform entry points (shared architecture and commands are on the platform overview pages):
- Simulation Platform · Walker TienKung Dex - Container build, launching simulation, batch collection, camera test, playback
- Imitation Learning Platform · Walker TienKung Dex - HDF5 -> LeRobot conversion, ACT training, offline evaluation, deployment parameters
In order of use:
- Simulation workflow - End to end: simulation collection -> conversion -> training -> evaluation -> sim deployment
- Real-robot workflow - End to end: real collection -> conversion -> training -> evaluation -> real deployment
- On-robot deployment - Docker-free deployment on the Thor board (venv + system Python dual stack)
Deployment results
Simulation
Real robot