Simulation Platform
ubt_sim is a robotics simulation platform built on NVIDIA Isaac Sim (Isaac Lab 2.2.0). It supports four robots: Walker TienKung Pro, Walker TienKung Dex, Walker S2 EDU, and Walker C1 EDU. A ROS2-ZMQ bridge publishes simulation state and images on exactly the same topics as the real robot, so teleoperation and data-collection scripts switch between simulation and hardware without modification, enabling seamless sim-to-real transfer. Main use cases:
- Simulation data collection: generate HDF5 training data in batches without occupying the real robot
- Algorithm validation: low-risk testing of imitation learning and control policies before real deployment
Architecture
Three processes (Python versions must not be mixed):
- Simulation
/isaac-sim/python.sh: loads the task scene selected byUBT_SIM_TASK(the task name also determines the robot type) and sends camera images directly over ZMQ. - Bridge
/usr/bin/python3: bidirectional ZMQ↔ROS 2 forwarding, started automatically bystart_sim.sh. - Collection
/usr/bin/python3: publishes commands and records 15 Hz HDF5.
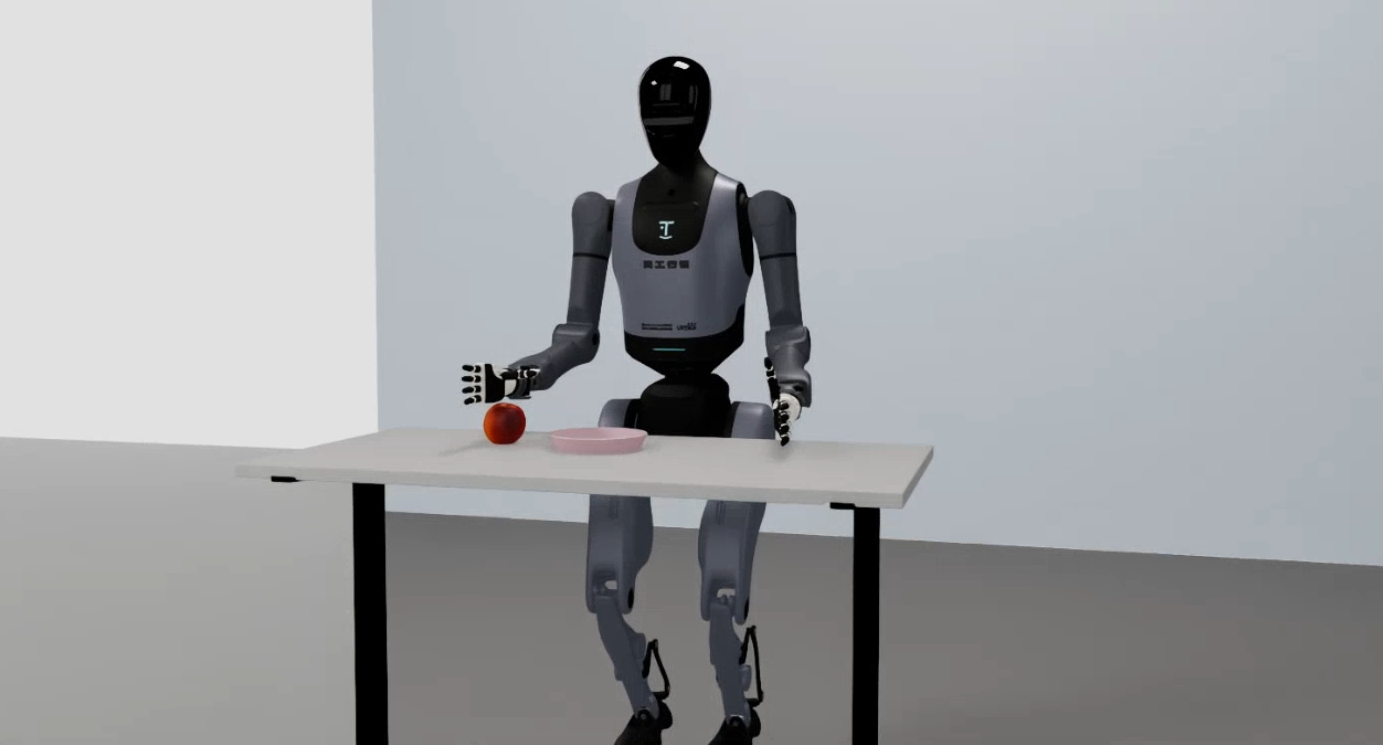
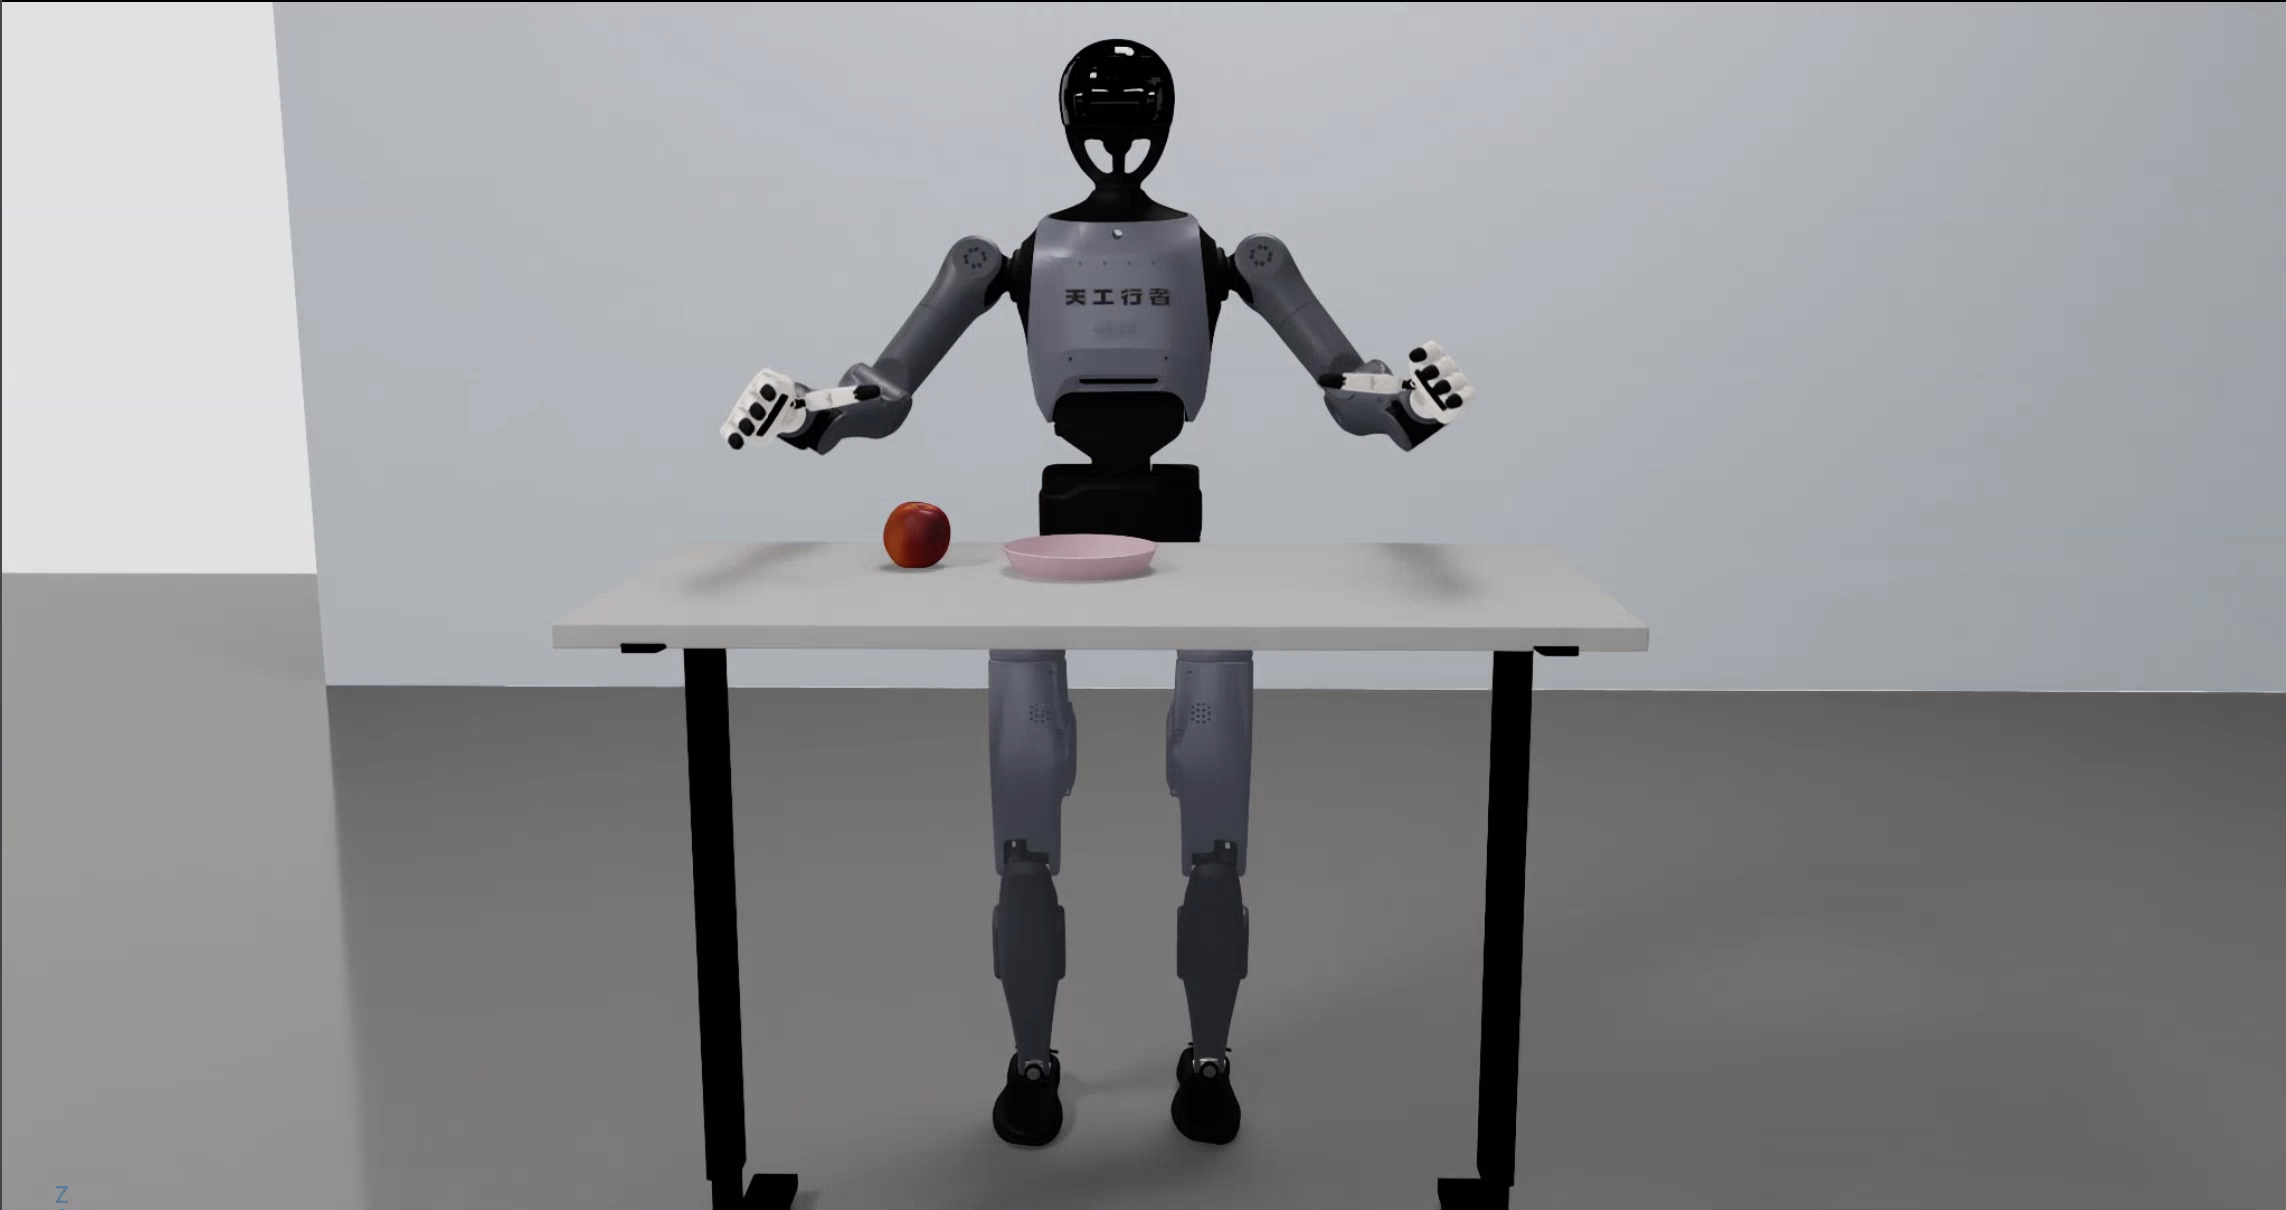
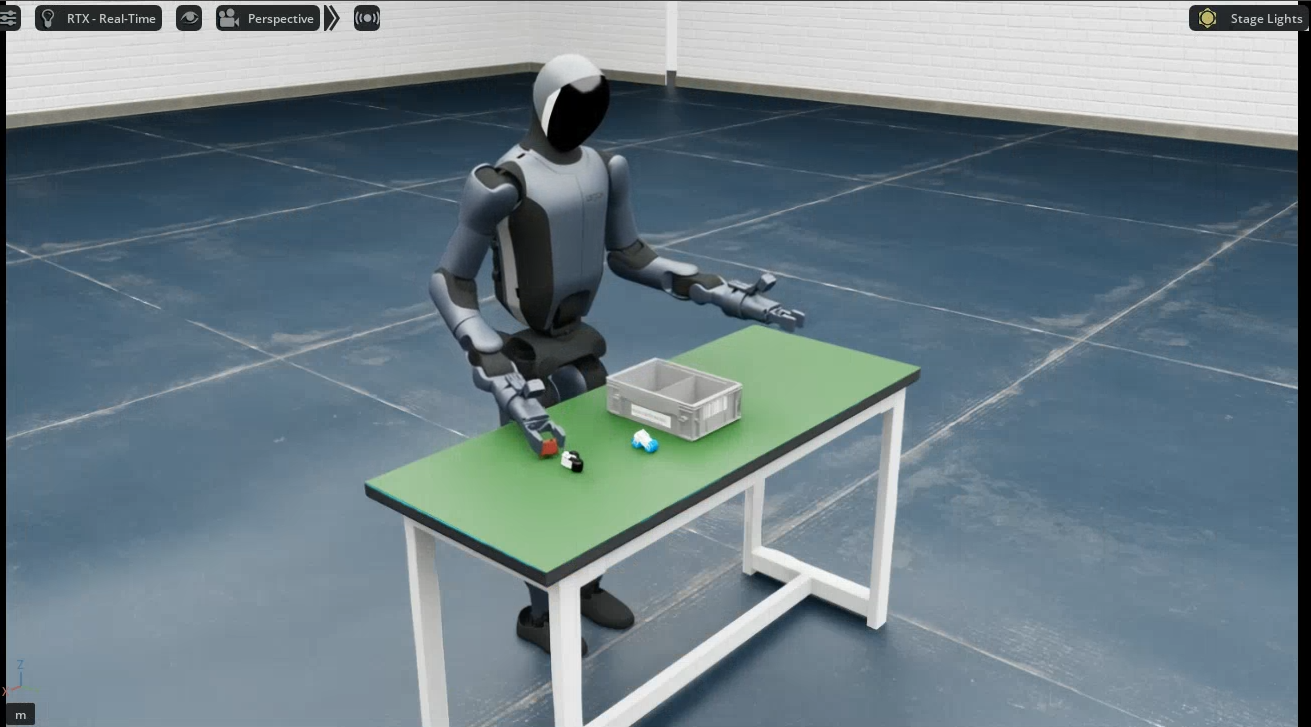
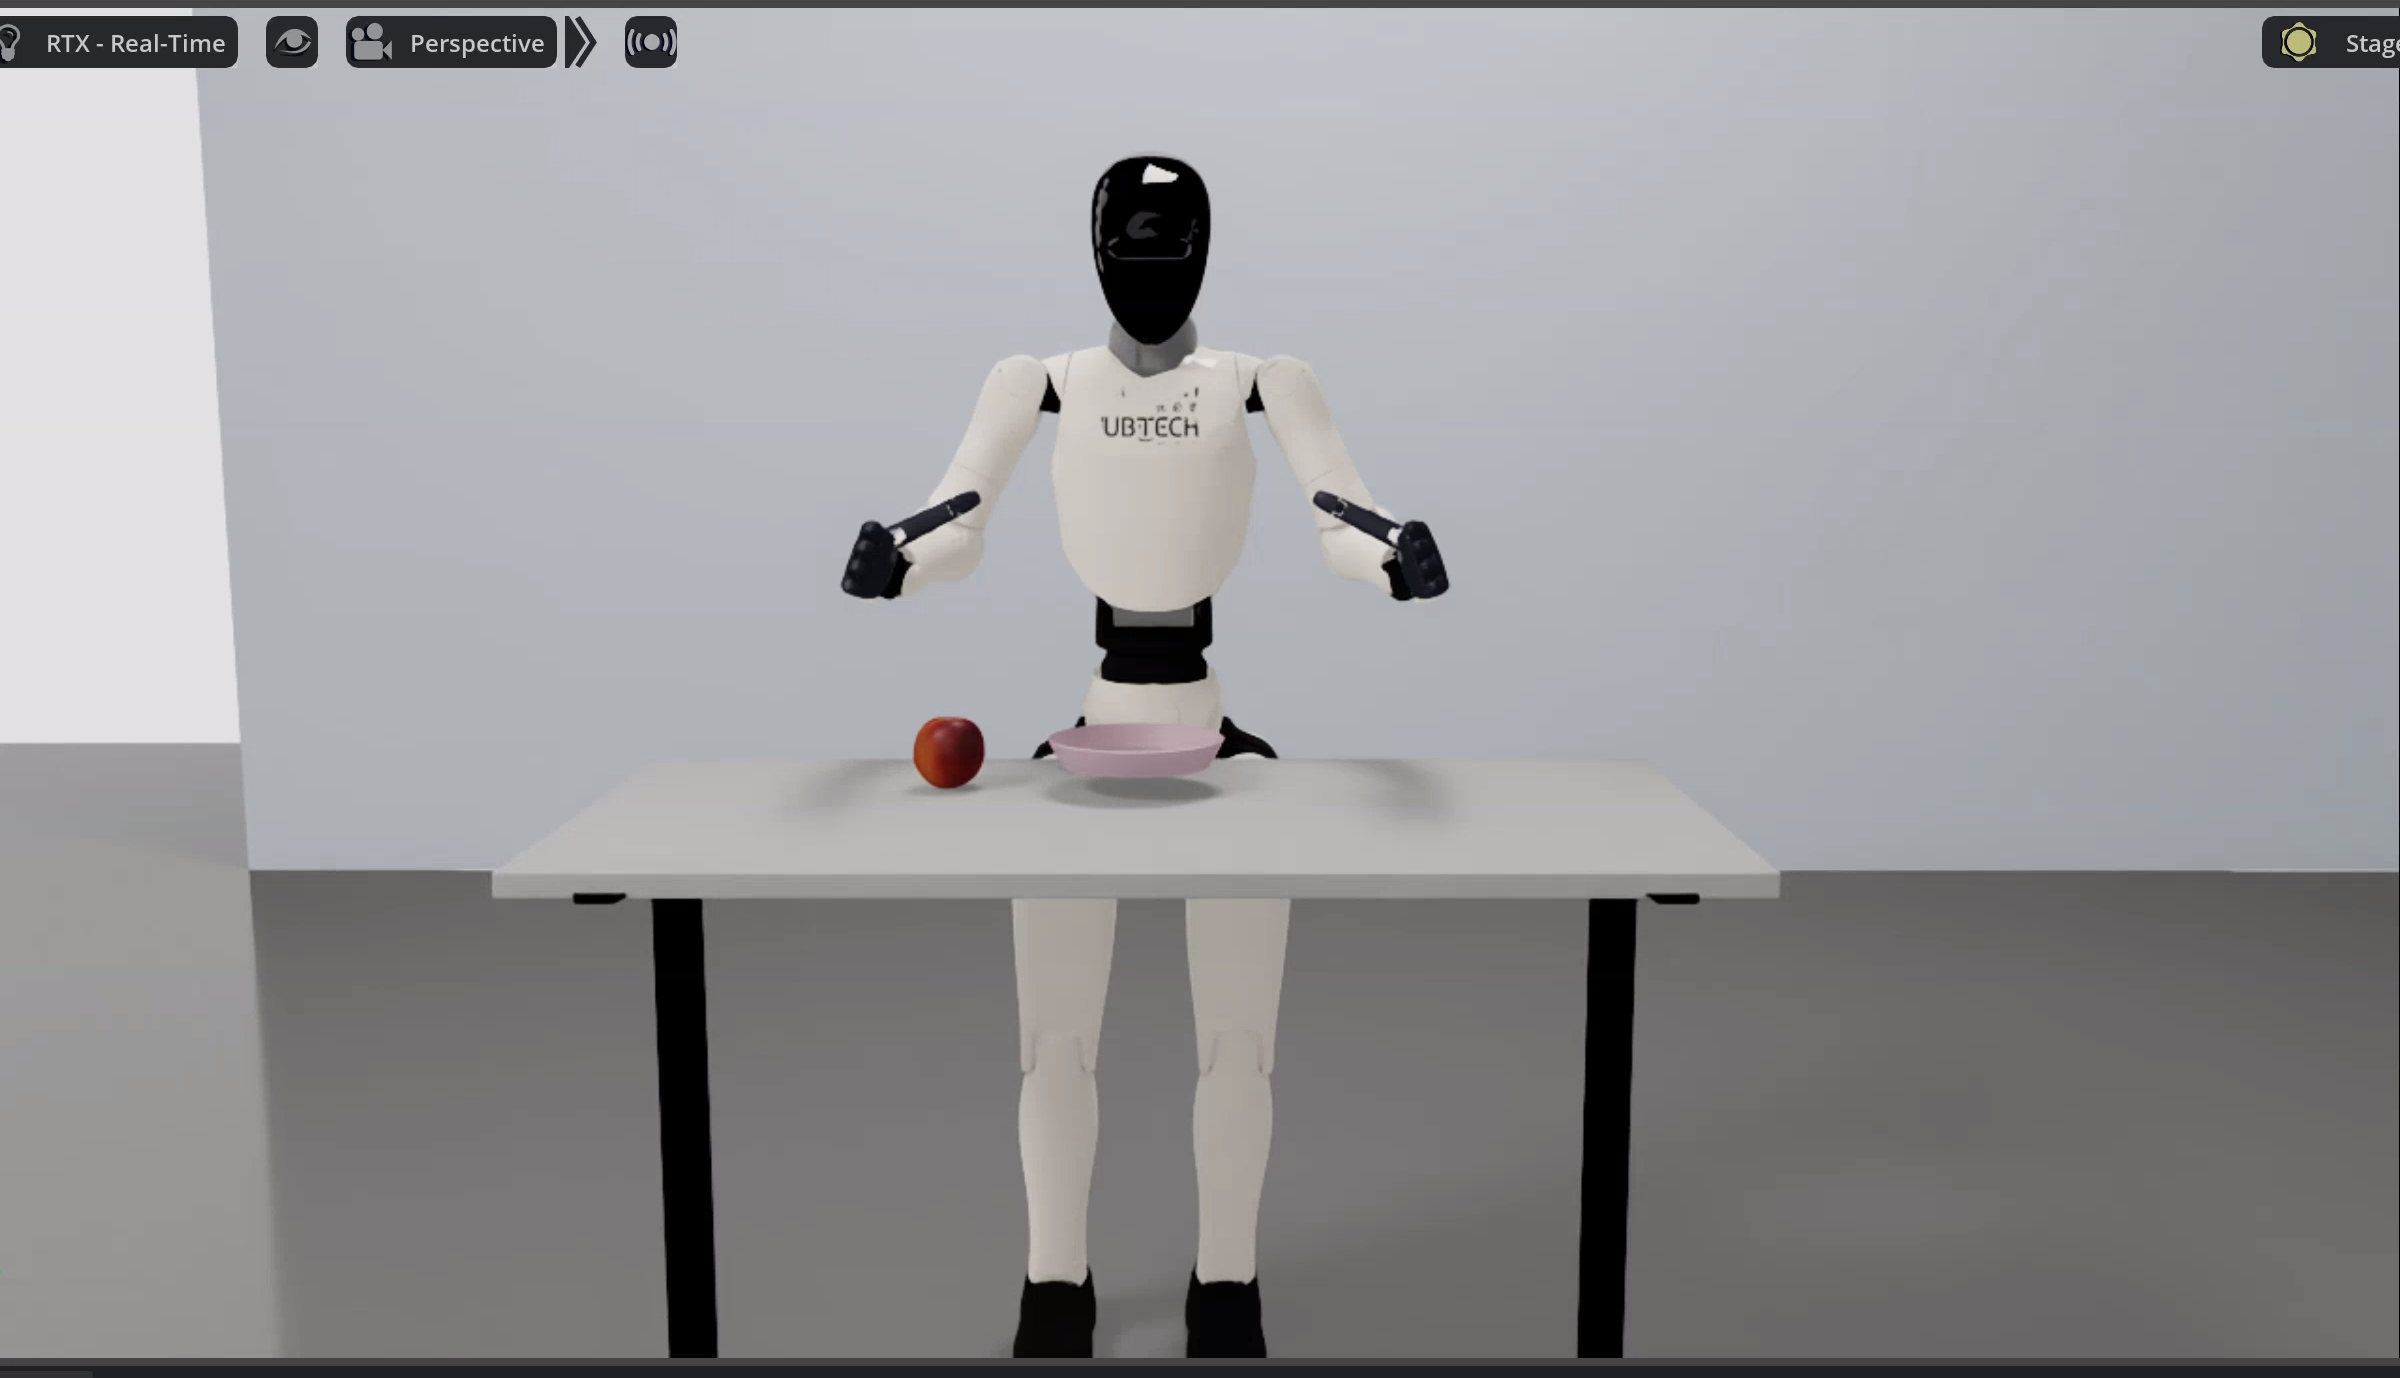
Simulation preview
Walker TienKung Pro
Walker TienKung Dex
Walker S2 EDU
Walker C1 EDU
Documentation
| Section | Description |
|---|---|
| Container setup | Shared container build, startup, and run.sh commands |
| Walker TienKung Pro | Parlor apple-picking scene, launching, batch collection, camera test, preview |
| Walker TienKung Dex | Inspire/BrainCo hands, apple picking, batch collection, playback |
| Walker S2 EDU | Part-sorting scene, batch collection, robot controller tools |
| Walker C1 EDU | Parlor pick-and-place, online IK collection, reset and playback |
After collection, continue with the Imitation Learning Platform. For full playback options, see Playback.