Walker C1 EDU
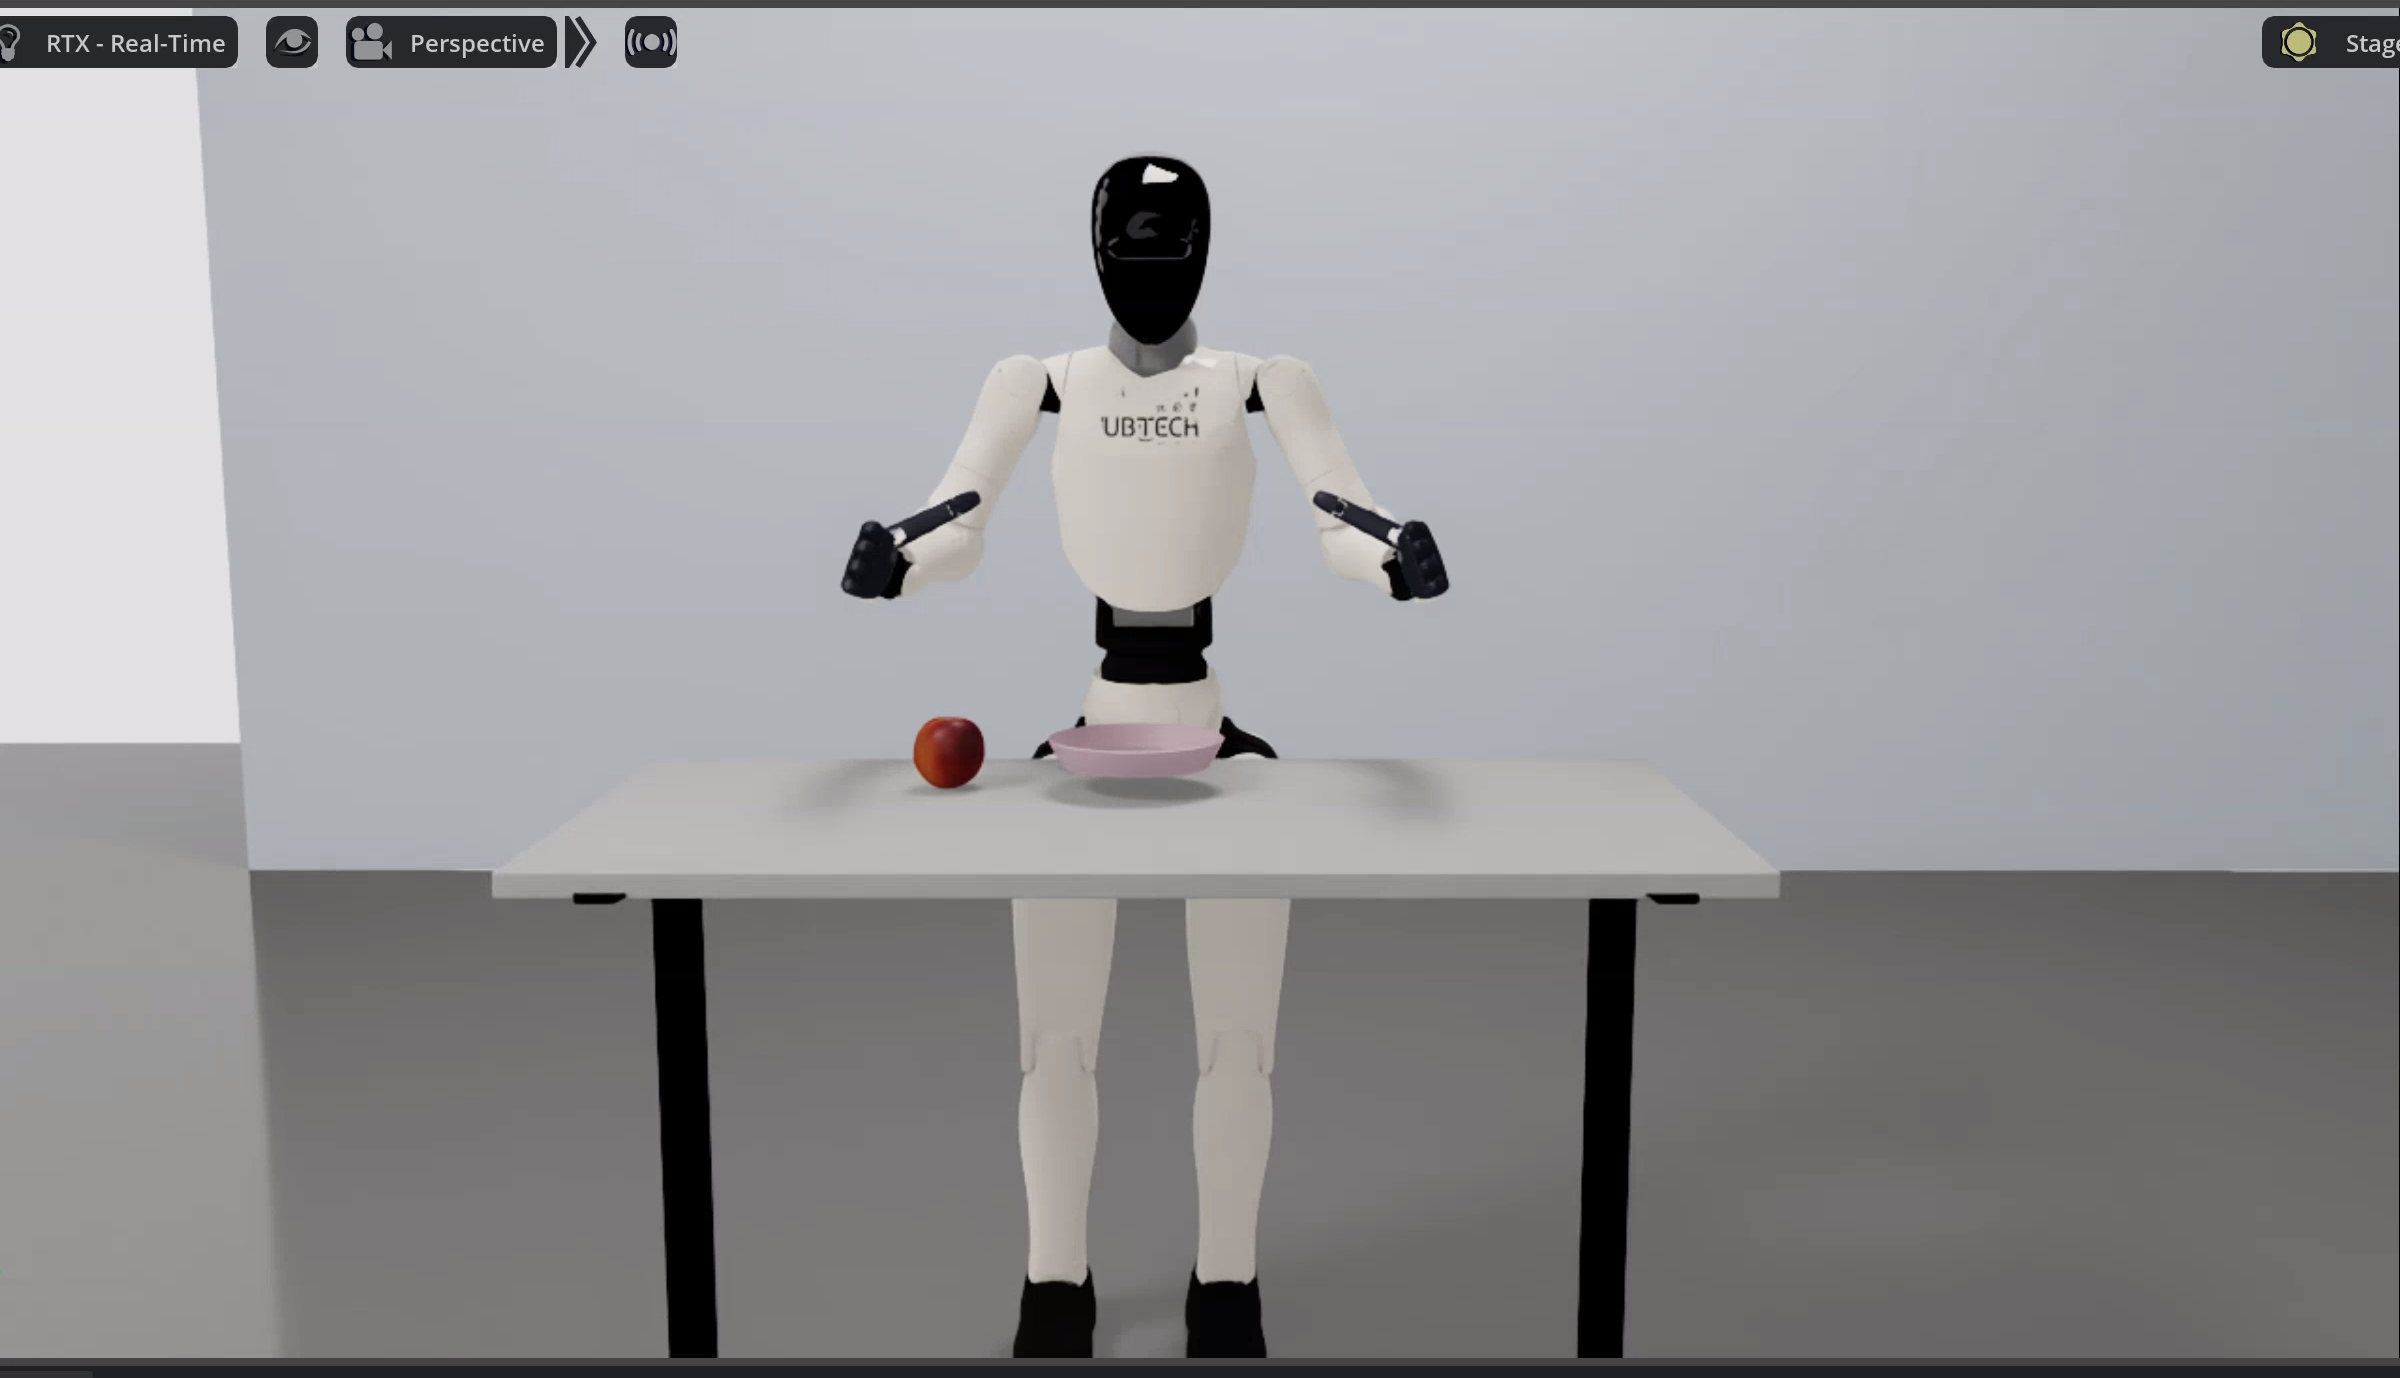
Walker C1 EDU is a humanoid robot with 53 DOF and 41 controllable upper-body joints. Each arm has 7 DOF; each hand is an 11-joint dexterous hand (exposed as 6 SDK channels); the head carries a monocular RGB camera.
Specifications
| Item | Specification |
|---|---|
| DOF | 53 (arms 14 + hands 11×2 + head 2 + waist 3 + legs 12) |
| End effectors | 2 × dexterous hands (11 joints each; 6 SDK channels: thumb_swing / thumb_mcp / index_mcp / middle_mcp / ring_mcp / little_mcp) |
| Common training dimensions | 26D (left arm 7 + right arm 7 + left hand 6 + right hand 6) / 13D (right arm 7 + right hand 6, single-arm tasks) |
| Joints not controlled by the policy | Head 2 / waist 3 / legs 12 (hold their current position; simulation anchors to HOME_POSE) |
| LeRobot plugin | ubt_IL/walker_c1/lerobot_robot_walker_c1 (robot type walker_c1) |
| USD model | ubt_sim/assets/robots/walker_c1/usd/walker_c1_with_hands.usd |
| Cameras | Head monocular RGB: simulation /sensor/camera/head/color/raw, real robot /sensor/camera/head_stereo_left/color/raw |
| Training resolution | Simulation 320×240; real robot 640×512 (5:4) |
| ROS domain | ROS_DOMAIN_ID=0 by default (simulation and real robot share domain 0; isolate by domain ID) |
Verified on hardware (Nov 2026): 13D (right arm 7 + right hand 6), 30 fps, head camera 640×512. Dataset
walker_c1_real_13d_1RGB(34 episodes / 11,406 frames) -> modelwalker_c1_real_13d_act_1RGB; the real-robot deployment loop is working.
Simulation task
| Task ID | Scene | Description |
|---|---|---|
UBTSim-WalkerC1-Parlor-v0 |
Parlor pick-and-place | Apple pick-and-place with online IK collection (default) |
Walker C1 EDU and Walker S2 EDU use the same simulation ZMQ ports (5655-5658); only one robot can run at a time.
Documentation
Platform entry points (shared architecture and commands are on the platform overview pages):
- Simulation Platform · Walker C1 EDU - Container build, launching simulation, batch collection, reset and playback
- Imitation Learning Platform · Walker C1 EDU - HDF5 -> LeRobot conversion, ACT training, offline evaluation, deployment parameters
In order of use:
- Simulation workflow - End to end: simulation collection -> conversion -> training -> evaluation -> sim deployment
- Real-robot workflow - End to end: half_sdk prerequisite -> real collection -> conversion -> training -> real deployment
- Real-robot deployment - half_sdk guard, ready/home poses, ROBOT_MODELS registry, safety prechecks
- Inference server - Warm start, ZMQ commands, remote launch, model hot-swap
- Architecture - 26D/13D contract, ZMQ ports, ROS 2 topics, hand mapping
Deployment results
Simulation
Real robot