Walker S2 EDU
Walker S2 EDU is a humanoid robot with 34 DOF, equipped with two PGC two-finger grippers (optionally two 7-DOF V4 dexterous hands).
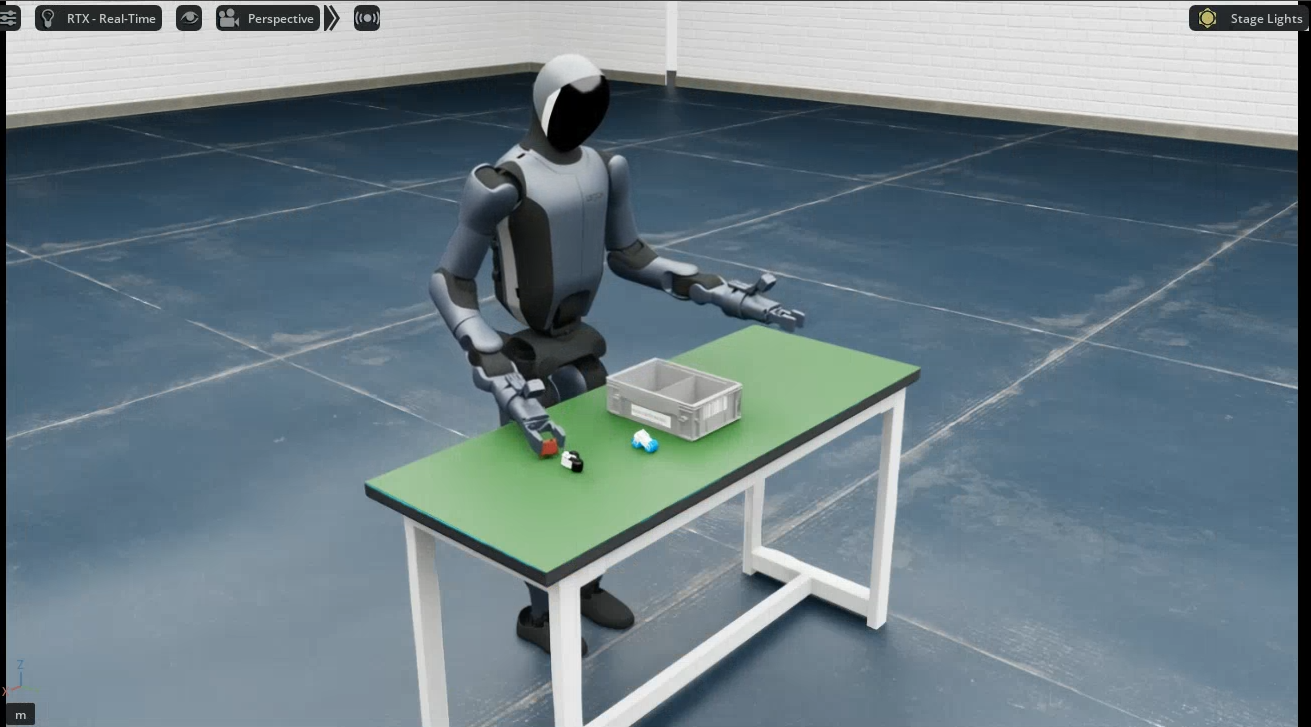
Specifications
| Item | Specification |
|---|---|
| DOF | 34 (17 body + hands) |
| End effectors | 2 × PGC two-finger grippers (optional 2 × 7-DOF V4 dexterous hands) |
| Common training dimensions | 10D (right arm 7 + head 2 + right gripper 1) / 19D (17 body + 2 grippers) / 31D (17 body + 2 V4 hands, 14) |
| LeRobot plugin | ubt_IL/walker/lerobot_robot_walker |
| USD model | ubt_sim/assets/robots/walker_s2/s2_v1.usd |
| Cameras | Four: head stereo left/right + wrist left/right |
Constant dimensions in single-arm / single-gripper data break normalization during training (QUANTILES NaN/Inf). For real-robot data, reduce the action space to 10D (right arm + head + right gripper).
Simulation tasks
| Task ID | Scene | Description |
|---|---|---|
UBTSim-WalkerS2-PartSorting-v0 |
Part sorting | 4 parts + bins (default) |
UBTSim-WalkerS2-PickPart-v0 |
Part sorting | Single-part picking: only one part remains on the table; use with pick_part.py |
Documentation
Platform entry points (shared architecture and commands are on the platform overview pages):
- Simulation Platform · Walker S2 EDU - Container build, launching simulation, batch collection, robot controller tools
- Imitation Learning Platform · Walker S2 EDU - HDF5 -> LeRobot conversion, ACT / Pi0.5 training, offline evaluation
In order of use:
- Simulation workflow - End to end: simulation collection -> conversion -> training -> evaluation -> sim deployment
- Real-robot workflow - End to end: real collection -> conversion -> training -> evaluation -> real deployment
- Real-robot deployment - Rollout details, safety prechecks, ROBOT_MODELS registry, online evaluation
- Inference server - Warm start, ZMQ commands, remote launch, model hot-swap
Deployment results
Simulation
Real robot