Walker C1 EDU Simulation Workflow: Collect -> Convert -> Train -> Evaluate -> Deploy
Robot: Walker C1 EDU Data source: Isaac Sim collection (
ubt_sim, taskUBTSim-WalkerC1-Parlor-v0) Container:lerobot-tienkung(built/started byubt_IL/docker/run.sh, project mounted at/ubt_IL)
This guide covers the complete workflow from raw simulation HDF5 to a LeRobot dataset, ACT training, offline evaluation, and finally feedback deployment into the simulator. All conversion/training/evaluation/deployment scripts run inside the ubt_IL container.
Contents
- 0. Workflow overview
- 1. Prerequisite: simulation collection (ubt_sim)
- 2. Start the container (ubt_IL)
- 3. Data conversion (HDF5 -> LeRobot)
- 3.1 Conversion command
- 3.2 Data visualization
- 4. Policy training
- 5. Policy evaluation (offline MSE)
- 6. Simulation deployment (closed-loop)
- 7. FAQ
0. Workflow overview
ubt_sim HDF5 ──► convert.sh ──► LeRobot dataset ──► lerobot-train ──► checkpoint
                                                                  │
                                                                  ├─► eval_policy.py (offline)
                                                                  └─► rollout.sh (sim closed loop)
| Stage | Command | Output |
|---|---|---|
| Simulation collection | ubt_sim/teleoperation/control/walker_c1/save_data.sh |
ubt_sim/dataset/walker_c1/<epoch>/trajectory.hdf5 |
| Conversion | scripts/convert/walker_c1/convert.sh |
ubt_IL/dataset/walker_c1_sim_{26d,13d}_1RGB |
| Training | scripts/train/walker_c1/train.sh |
ubt_IL/model/walker_c1_sim_26d_act_1RGB |
| Evaluation | scripts/eval/eval_policy.py |
scripts/eval/output/.../results.json |
| Deployment | scripts/deploy/walker_c1/rollout.sh |
Simulated arm motion |
1. Prerequisite: simulation collection (ubt_sim)
See Simulation Platform for scene, reset, and playback details.
# ① Launch simulation inside the ubt_sim container (separate terminal)
UBT_SIM_ROBOT=walker_c1 bash run.sh bash
bash scripts/start_c1_pick_place_sim.sh        # or UBT_SIM_TASK=UBTSim-WalkerC1-Parlor-v0 bash scripts/start_sim.sh

# ② Collect: one episode by default; --batch 20 randomizes object poses
bash teleoperation/control/walker_c1/save_data.sh --batch 20
- In the simulation window,
Rresets the scene andSpacerequests saving the current episode. - Output:
ubt_sim/dataset/walker_c1/<epoch seconds>/trajectory.hdf5, 15 Hz, onecamera_headstream at 640×480 PNG. - Before collecting, confirm
/mc/sdk/robot_stateis publishing (about 48 Hz) and hand gains are 10/1 with effort 2 N·m.
2. Start the container (ubt_IL)
cd ubt_IL/docker
bash run.sh build      # first time; Thor switches to Dockerfile.thor automatically
bash run.sh start
bash run.sh check      # expect [OK] for walker_c1 plugin / bridge / ROS2 msgs
bash run.sh bash       # enter the container; run the remaining commands there
Inside the container, /ubt_sim is a read-only mount. If ls /ubt_sim fails, the container was created with an old mount; rebuild it with bash run.sh rm && bash run.sh start.
3. Data conversion (HDF5 -> LeRobot)
Simulation data is written to ubt_sim/dataset/walker_c1/<epoch seconds>/trajectory.hdf5. The ubt_IL container mounts ubt_sim/ read-only at /ubt_sim, so conversion reads it directly without copying.
3.1 Conversion command
# Convert one episode first to validate the pipeline
bash /ubt_IL/scripts/convert/walker_c1/convert.sh --save_one true --overwrite

# Full run (26D: both arms + both hands)
bash /ubt_IL/scripts/convert/walker_c1/convert.sh --overwrite

# 13D (right arm + right hand, single-arm task)
DIM=13 bash /ubt_IL/scripts/convert/walker_c1/convert.sh --overwrite
Defaults: DIM=26, CONFIG=configs/walker_c1_sim_26d_1RGB.json, REPO_ID=walker_c1_sim_26d_1RGB, FPS=15, TASK_NAME=walker_c1_sim_pick_place, HDF5_REL_PATH=trajectory.hdf5, TAIL_TRIM=10.
Common overrides: REPO_ID, TASK_NAME, FPS, SRC_ROOT, TGT_PATH, TRIM_STATIONARY. Run bash convert.sh --help for all options.
Validation:
python - <<'PY'
import json
info = json.load(open("/ubt_IL/dataset/walker_c1_sim_26d_1RGB/meta/info.json"))
print(info["total_episodes"], info["features"]["observation.state"]["shape"],
      info["features"]["observation.images.camera_head"]["shape"])
PY
Expected output: 11 [26] [3, 240, 320] (the episode count depends on how much data was collected).
The repository ships about 11 episodes × 100 frames, enough only for smoke tests and pipeline validation. Collect more data for real simulation training (50+ episodes recommended).
3.2 Data visualization
HF_HUB_OFFLINE=1 lerobot-dataset-viz \
  --repo-id walker_c1_sim_26d_1RGB \
  --episode-index 0 \
  --root /ubt_IL/dataset/walker_c1_sim_26d_1RGB
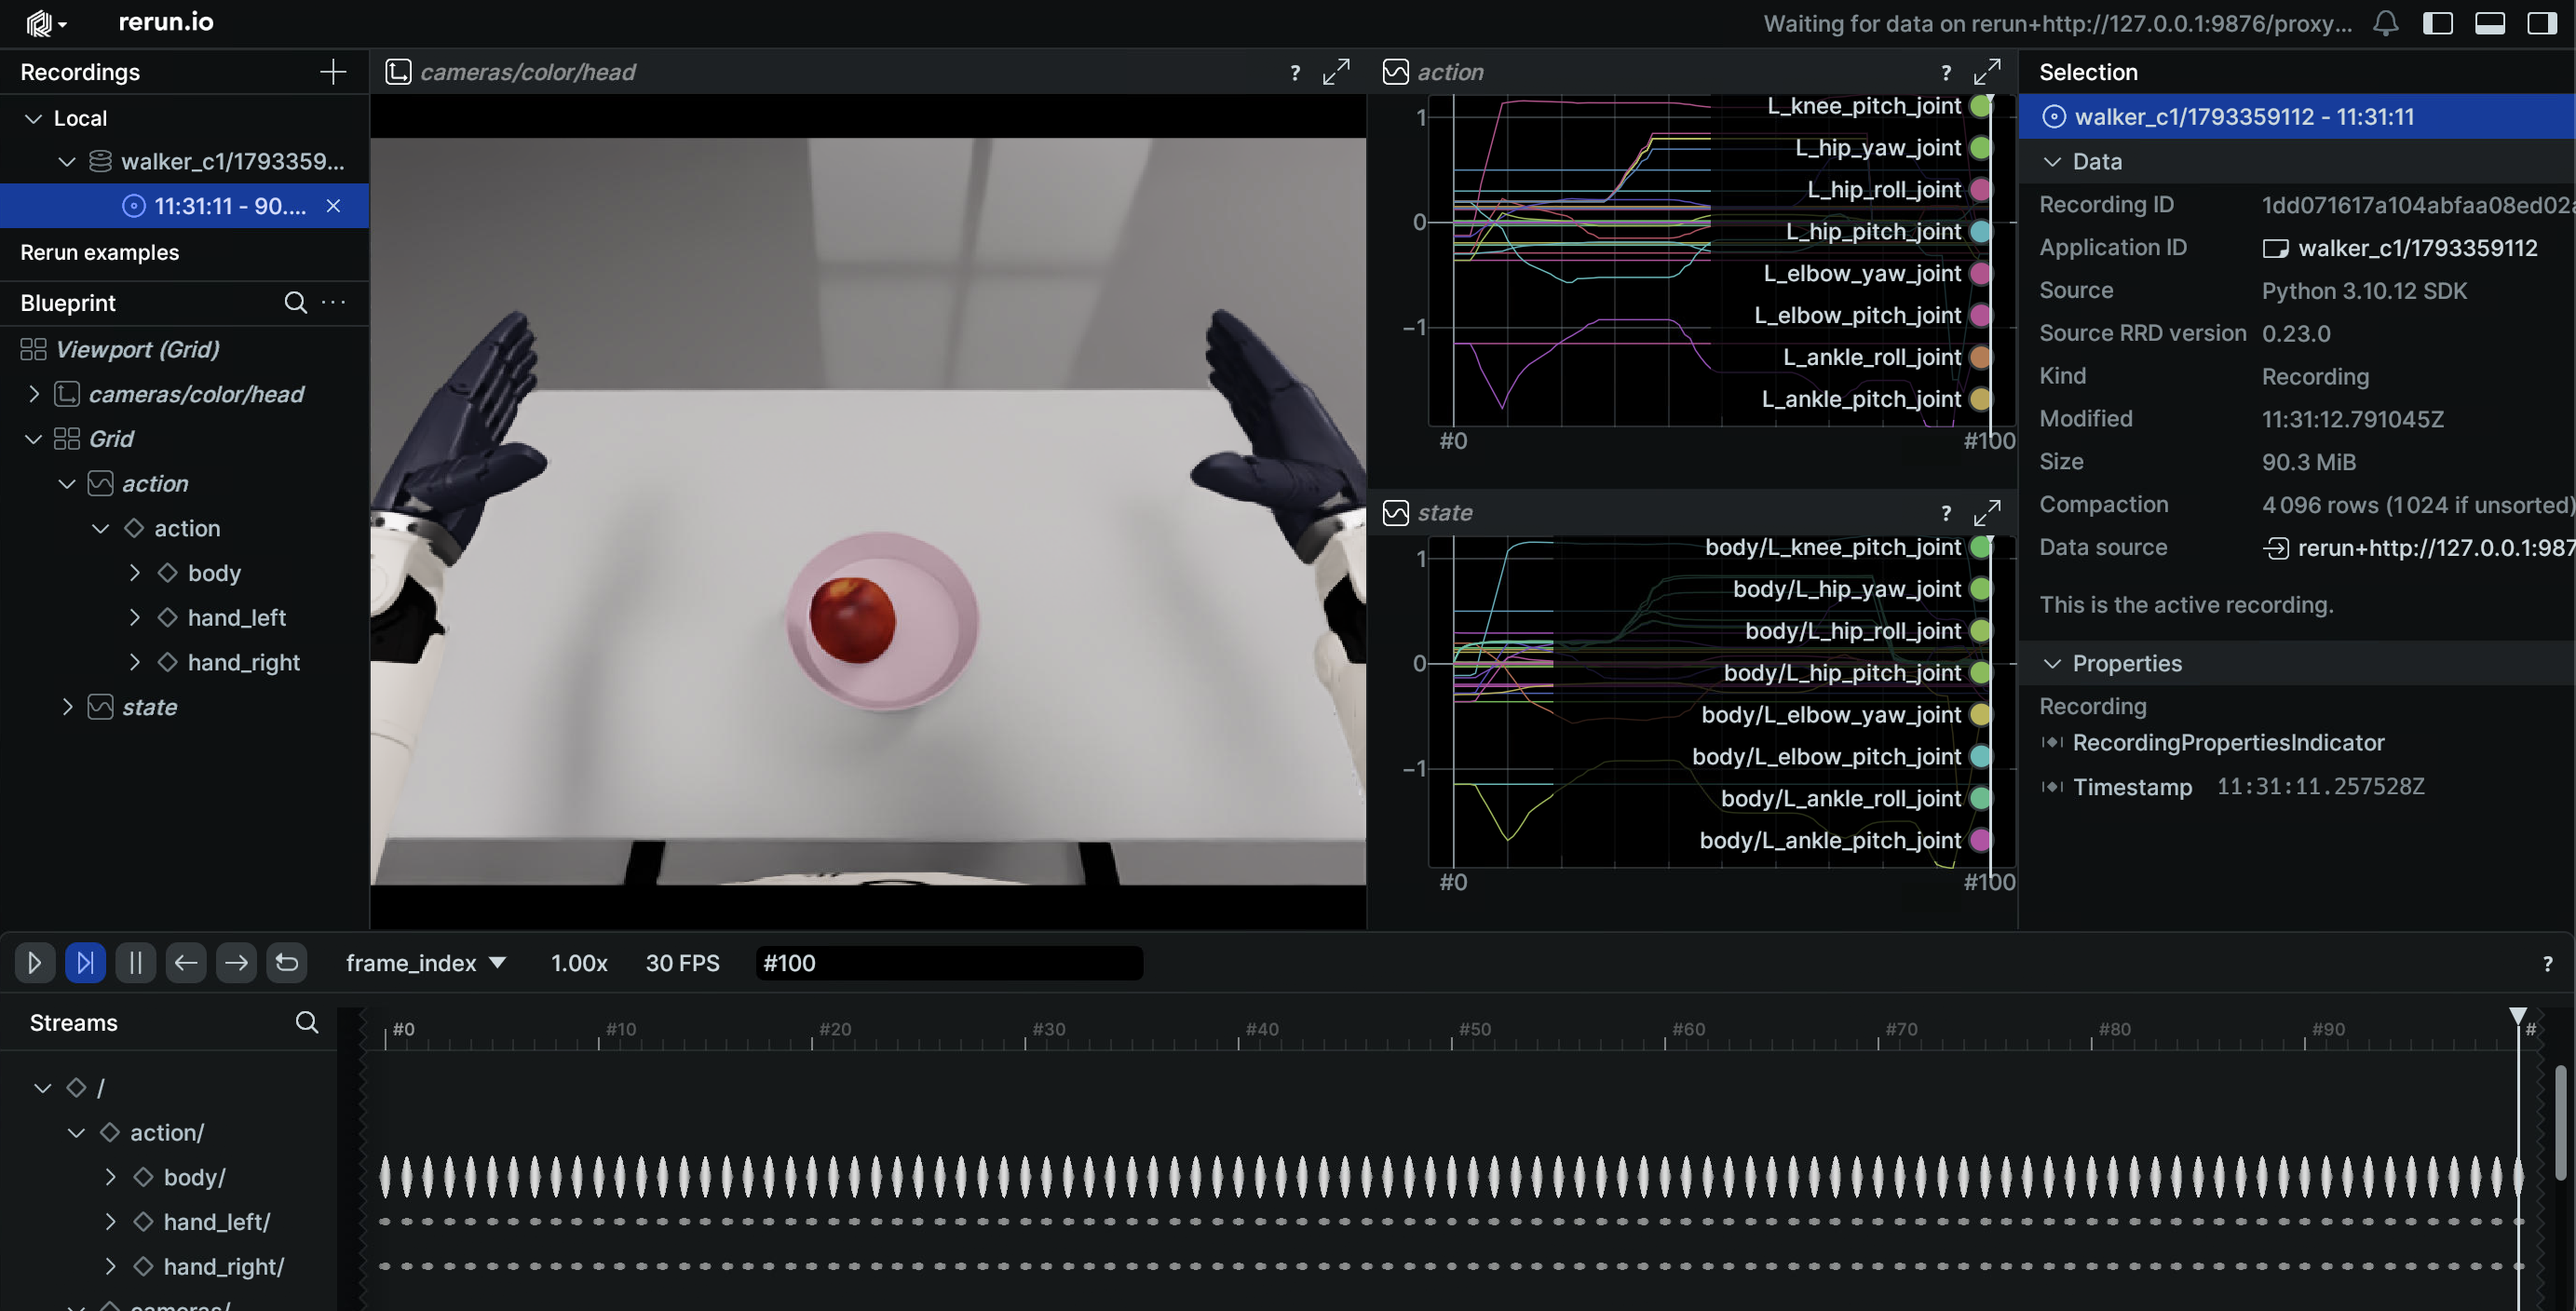
--rootmust point to the dataset directory containingmeta/;--episode-indexvisualizes one episode at a time.
4. Policy training
# Smoke test: 2 steps, no checkpoint
bash /ubt_IL/scripts/train/walker_c1/train.sh --steps=2 --save_checkpoint=false

# Full training (default ACT / 26D simulation config)
bash /ubt_IL/scripts/train/walker_c1/train.sh

# Override common parameters
OUTPUT_DIR=/ubt_IL/model/walker_c1_sim_26d_act_1RGB_v2 \
STEPS=50000 SAVE_FREQ=5000 BATCH_SIZE=8 \
bash /ubt_IL/scripts/train/walker_c1/train.sh

# Resume (CONFIG points to train_config.json inside the checkpoint)
CONFIG=/ubt_IL/model/walker_c1_sim_26d_act_1RGB/checkpoints/last/pretrained_model/train_config.json \
RESUME=true bash /ubt_IL/scripts/train/walker_c1/train.sh
Key config (configs/train_config_walker_c1_sim_act_26d_1RGB.json):
| Item | Value |
|---|---|
| Policy | ACT, chunk_size=n_action_steps=100 |
| Input | observation.images.camera_head [3,240,320] + observation.state [26] |
| Output | action [26] |
| Training | batch_size=8, steps=30000, save_freq=5000 |
Output: checkpoints/<step>/pretrained_model (with config.json + model.safetensors) and checkpoints/last.
5. Policy evaluation (offline MSE)
/lerobot/.venv/bin/python /ubt_IL/scripts/eval/eval_policy.py \
  --policy-path /ubt_IL/model/walker_c1_sim_26d_act_1RGB/checkpoints/last/pretrained_model \
  --dataset-path /ubt_IL/dataset/walker_c1_sim_26d_1RGB \
  --episodes 5 \
  --inference-freq 15 \
  --plot \
  --plot-dir /ubt_IL/scripts/eval/output/eval_walker_c1_sim_26d_act \
  --output /ubt_IL/scripts/eval/output/eval_walker_c1_sim_26d_act/results.json \
  --device cuda
--inference-freq 15 emulates a 15 Hz deployment cadence; --plot writes per-joint GT-vs-prediction curves to --plot-dir (one per episode).
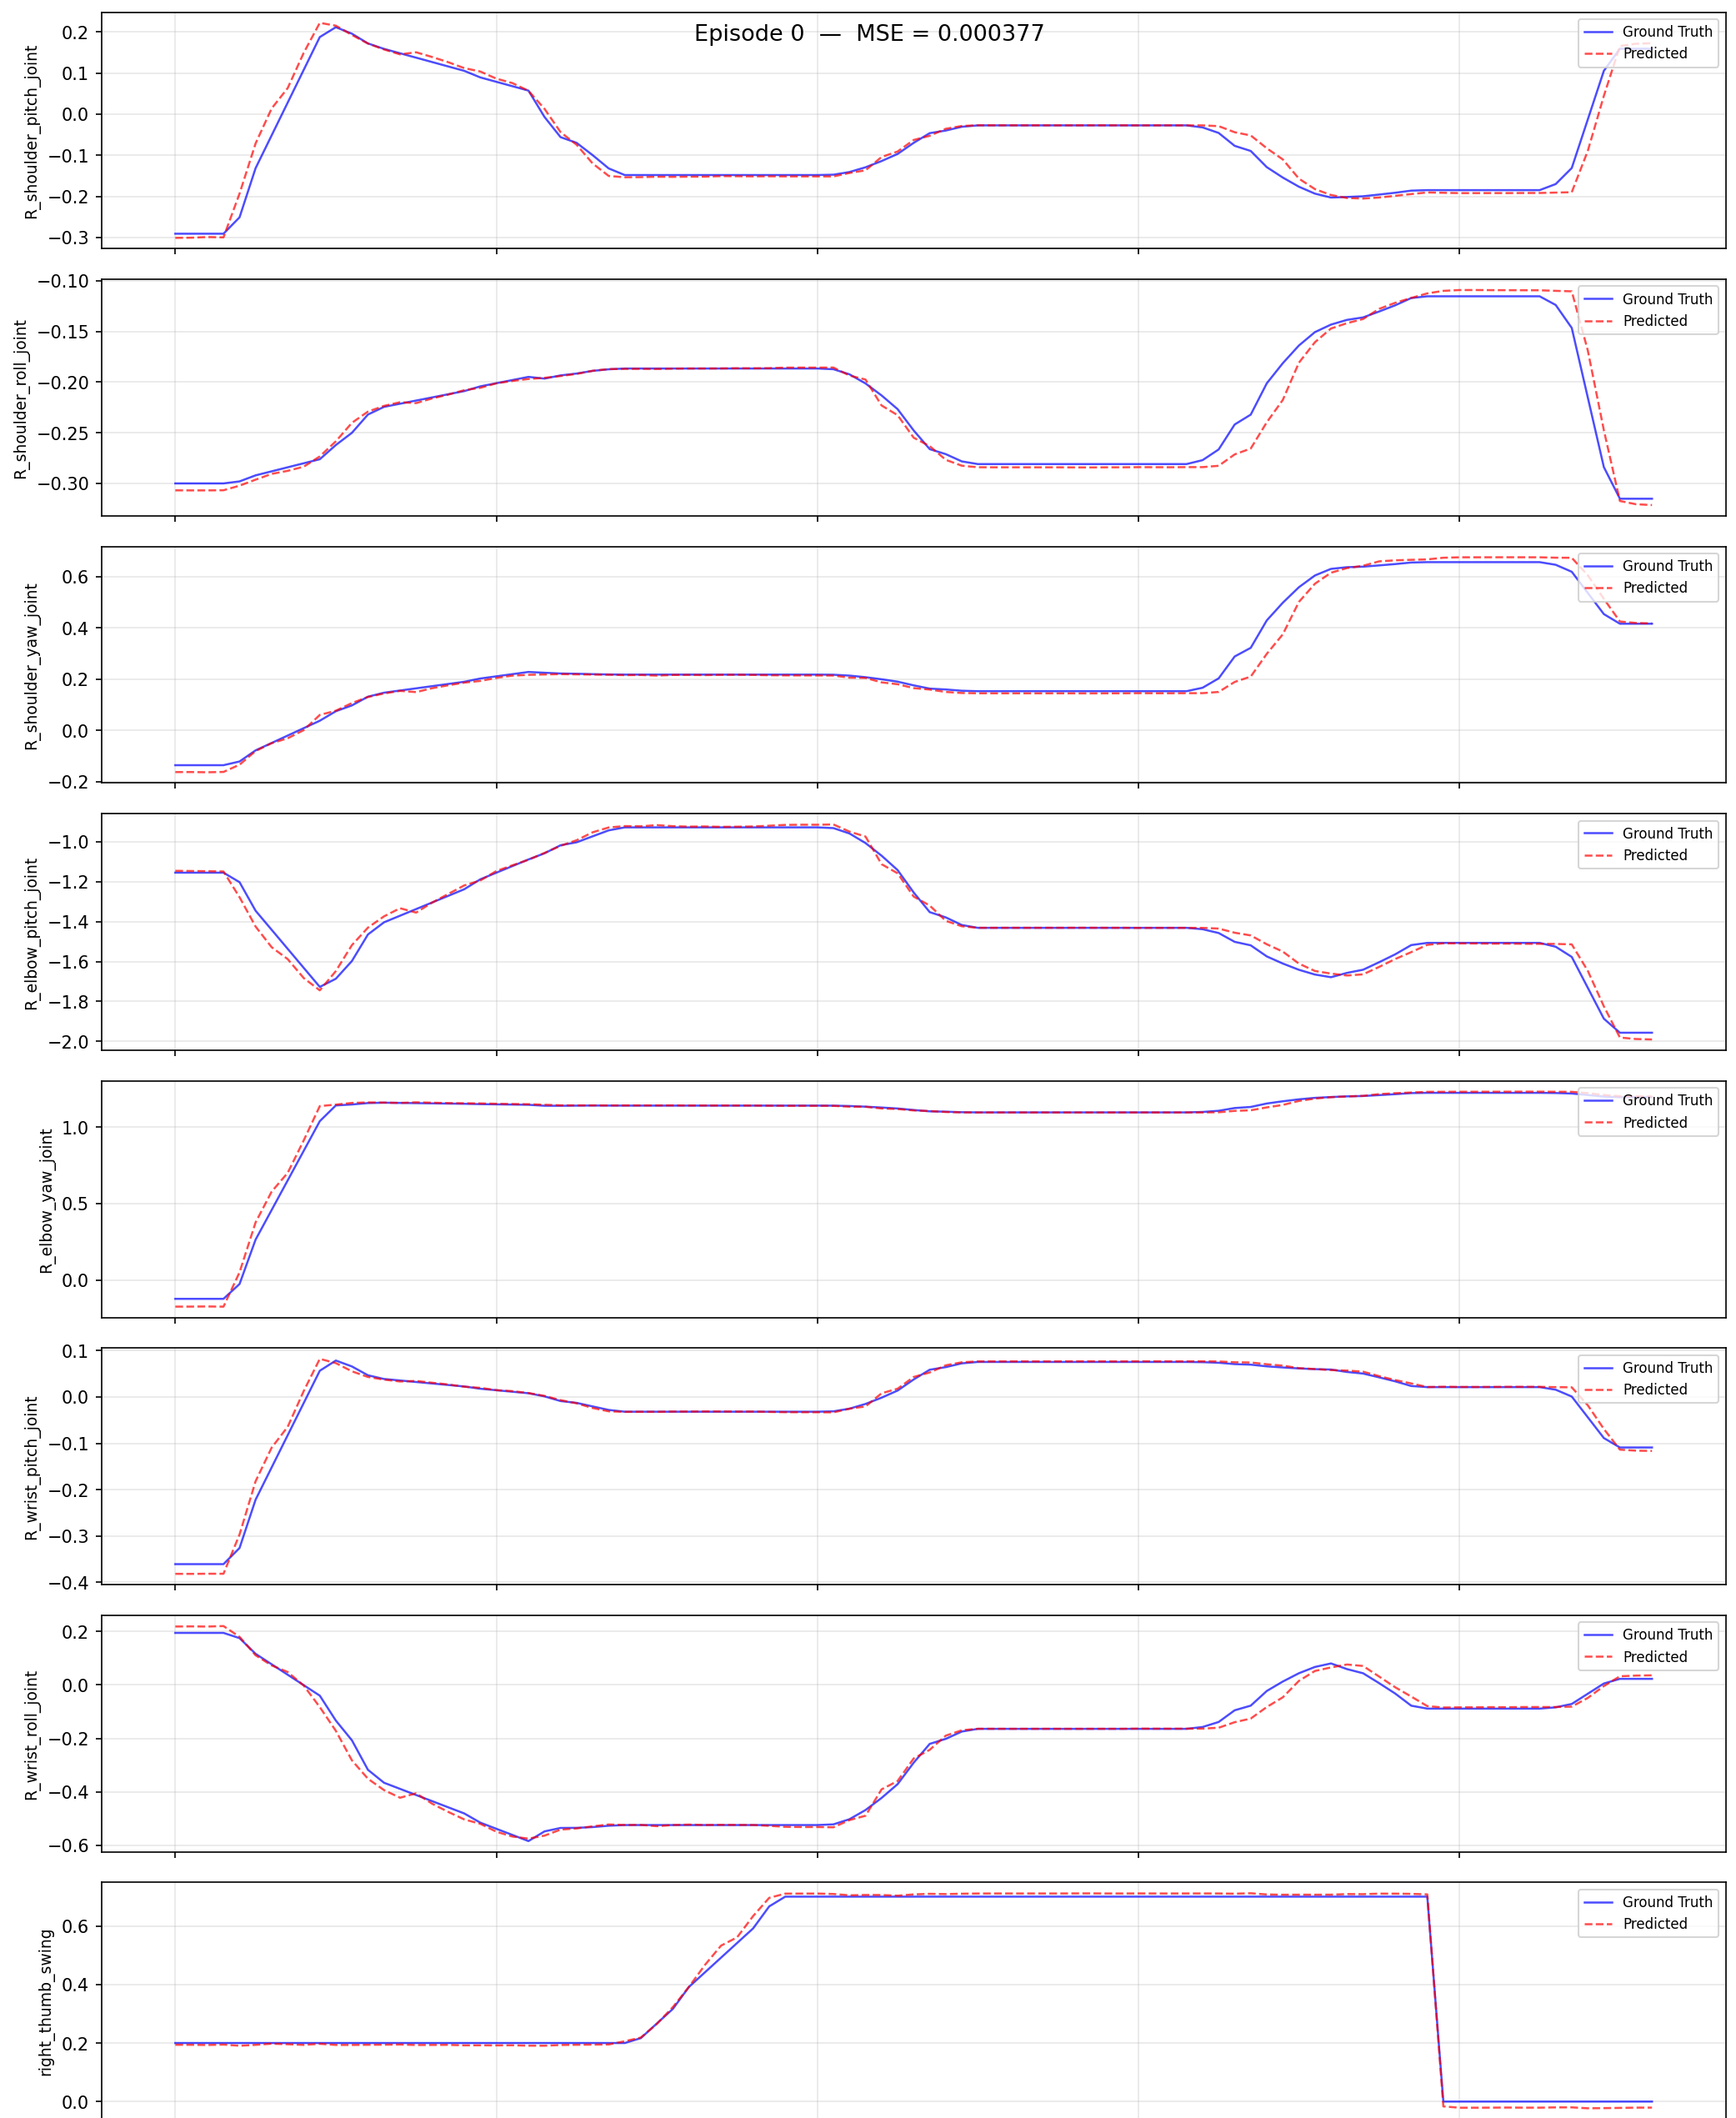
You can also run a single-frame inference check:
python /ubt_IL/scripts/deploy/walker_c1/infer_check.py \
  --checkpoint /ubt_IL/model/walker_c1_sim_26d_act_1RGB/checkpoints/last/pretrained_model \
  --dataset /ubt_IL/dataset/walker_c1_sim_26d_1RGB --frame 0
6. Simulation deployment (closed-loop)
# ① Confirm simulation is running (ubt_sim container) and the ROS domain matches
export ROS_DOMAIN_ID=0        # must be identical for simulation and deployment (ubt_sim defaults to 0; set both to 146 to isolate)

# ② Camera
python3 /ubt_IL/scripts/deploy/walker_c1/preview_camera.py --once --save-frame /tmp/c1.jpg

# ③ Reset + ready pose (three stages)
bash /ubt_IL/scripts/deploy/walker_c1/robot_ready.sh

# ④ rollout (WALKER_C1_REAL=0 for simulation)
WALKER_C1_REAL=0 SDK_GUARD=0 RESET_MODE=sim-scene \
POLICY_PATH=/ubt_IL/model/walker_c1_sim_26d_act_1RGB/checkpoints/last/pretrained_model \
  bash /ubt_IL/scripts/deploy/walker_c1/rollout.sh

# ⑤ Multiple episodes (reset + restart per episode; the base strategy does not support --strategy.num_episodes)
EPISODES=5 DURATION=20 RESET_MODE=both \
WALKER_C1_REAL=0 SDK_GUARD=0 \
POLICY_PATH=/ubt_IL/model/walker_c1_sim_26d_act_1RGB/checkpoints/last/pretrained_model \
  bash /ubt_IL/scripts/deploy/walker_c1/rollout.sh
Ports: C1 plugin 5661/5662/5663; ubt_sim C1 bridge 5655-5658; both can run together. For a 13D model add ROBOT_MODEL=walker_c1_13d (simulation defaults to walker_c1_26d).
Demo:
7. FAQ
| Symptom | Fix |
|---|---|
| Conversion reports "Found 0 episodes" | No */trajectory.hdf5 under SRC_ROOT; verify HDF5_REL_PATH |
meta/info.json shows 640×480 images |
The config was modified; it should be image_size: [320,240] |
| Training loss does not decrease | Too little data (about 11 episodes); collect more or reduce dim_model |
| rollout dimension precheck fails | Policy dimension and ROBOT_MODEL disagree (26D / 13D), or ROBOT_CONFIG points to another robot's config |
| Head/waist/legs slowly sink | Joints not commanded by the simulator should hold HOME_POSE; check that no external node is publishing them |
| No camera image | Check preview_camera.py --topic, ROS_DOMAIN_ID, and QoS (BEST_EFFORT) |
| Motion is very slow / stutters | Increase FPS; use INFERENCE_TYPE=act_async INFERENCE_HZ=2 |
| Apple missed / knocked away | Residual state after reset is dirty: restart sim_runner, restore the apple with /sim/cmd_set_object_pose, then rerun robot_ready.sh |