Walker C1 EDU: Real-Robot Deployment (Rollout)¶
Deployment script:
ubt_IL/scripts/deploy/walker_c1/rollout.sh, shared by simulation and real-robot deployment (differences are described in the workflow pages). This page covers all parameters, the half_sdk guard, safety prechecks, and online evaluation.
Prerequisites¶
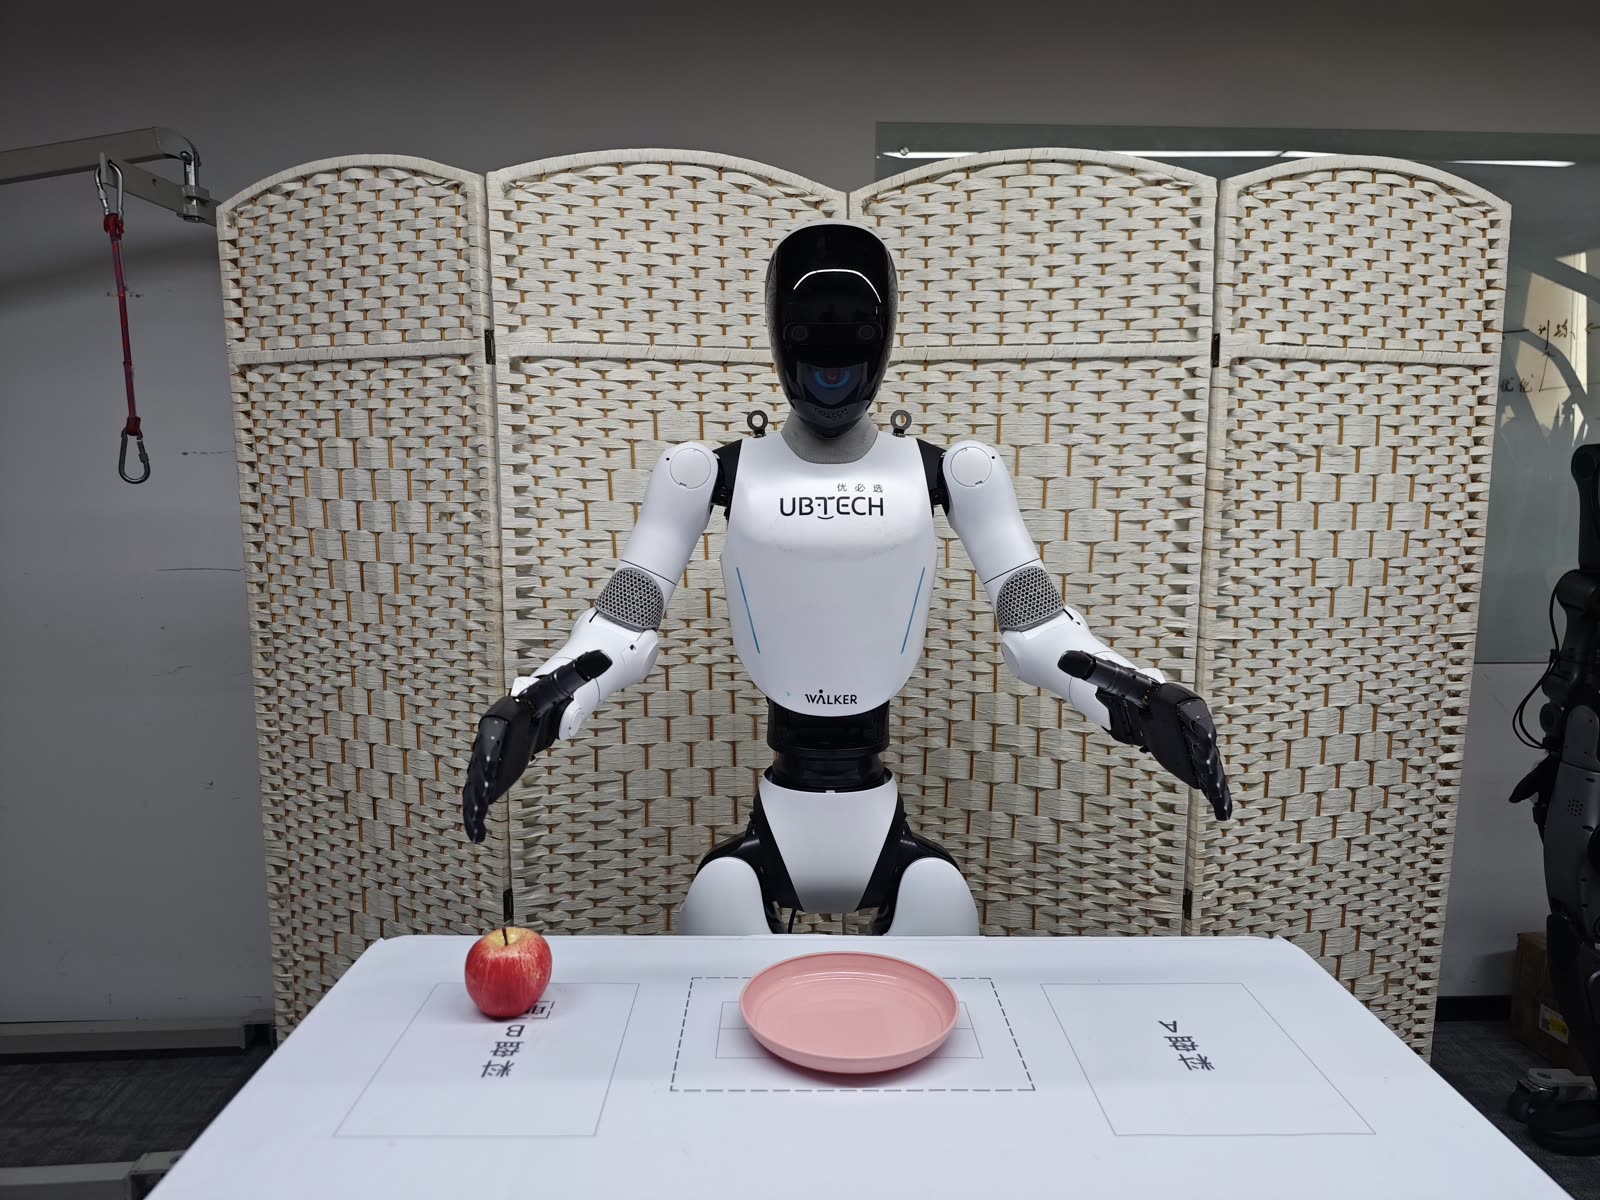
- The robot is powered, standing, and switched to developer mode + half_sdk (C1 arms accept ROS 2 commands only in
HalfSdkActive). - Place the robot in a safe position; use
DURATION=10for the first short validation; keep the emergency stop within reach. - The real-robot deployment container runs on the robot's Thor board. Copy the project and model to the board, then build and start the container (
run.shdetects Thor and switches toDockerfile.thor). ROS_DOMAIN_IDdefaults to0on hardware. DDS must match the main control stack (rmw_cyclonedds_cpp+cyclonedds_thor.xml, injected automatically by the container).
Deployment matrix¶
| Scenario | Key command |
|---|---|
| Real robot, 13D model (right arm + right hand) | WALKER_C1_REAL=1 ROBOT_MODEL=walker_c1_13d |
| Real robot, 26D model (both arms + both hands) | WALKER_C1_REAL=1 ROBOT_MODEL=walker_c1_26d |
| Feedback into simulation | WALKER_C1_REAL=0 SDK_GUARD=0 RESET_MODE=sim-scene |
| Long-running deployment | Use the inference server (no cold start) |
Deployment steps (real robot)¶
# 0. Switch to SDK control (developer mode -> legs STAND -> half_sdk; idempotent)
bash /ubt_IL/scripts/deploy/walker_c1/sdk_mode.sh half_sdk
bash /ubt_IL/scripts/deploy/walker_c1/sdk_mode.sh check      # 0 = deployable, 2 = not satisfied

# 1. Camera check (real head left, shm_msgs/Image6m)
python3 /ubt_IL/scripts/deploy/walker_c1/preview_camera.py --once --save-frame /tmp/c1.jpg \
  --msg-type image6m --topic /sensor/camera/head_stereo_left/color/raw

# 2. Move to the ready pose (three stages; dry-run first to inspect targets and durations)
bash /ubt_IL/scripts/deploy/walker_c1/robot_ready.sh --dry-run
bash /ubt_IL/scripts/deploy/walker_c1/robot_ready.sh

# 3. Deploy the real-robot 13D model (async inference)
WALKER_C1_REAL=1 SDK_GUARD=1 \
POLICY_PATH=/ubt_IL/model/walker_c1_real_13d_act_1RGB/checkpoints/last/pretrained_model \
ROBOT_MODEL=walker_c1_13d \
INFERENCE_TYPE=act_async INFERENCE_HZ=1 \
FPS=30 DURATION=10 \
  bash /ubt_IL/scripts/deploy/walker_c1/rollout.sh

# 4. Return home (14 arm joints at 0, arms straight down, hands open)
bash /ubt_IL/scripts/deploy/walker_c1/robot_home.sh --dry-run
bash /ubt_IL/scripts/deploy/walker_c1/robot_home.sh
Demo¶
SDK modes (half_sdk)¶
developModeState |
Arm commands | Notes |
|---|---|---|
NormalActive (normal) |
Ignored | Built-in motion control owns the body; only CC-API skills can be invoked |
HalfSdkActive (half_sdk) |
Executed | The only mode for VLA: SDK controls head/arms/waist, the system keeps balance (requires legStatus=standing) |
FullSdkActive (full_sdk) |
Executed | All motors handed over, built-in balance disabled; the robot must be suspended. Do not use for VLA |
bash sdk_mode.sh status     # work mode / motion permission / legs / e-stop
bash sdk_mode.sh check      # validate only, 0 = deployable, 2 = not satisfied
bash sdk_mode.sh half_sdk   # develop -> legs STAND -> half_sdk
bash sdk_mode.sh normal     # back to normal (keep developer mode)
bash sdk_mode.sh work-mode joystick   # exit developer mode
- By default commands run over SSH in the robot developer container (
ubt@192.168.11.3:2222). For CI/scripted use, setWALKER_C1_SDK_PASSWORDfor non-interactive login. half_sdkis idempotent: if already in half_sdk it only prints the state. If the legs are notstanding, it first runs skillA000004to switch to STAND (--no-leg-standdisables this).
Deployment guard¶
rollout.sh, robot_ready.sh / robot_home.sh (without --dry-run), and inference_server.sh call sdk_guard.sh before startup and refuse to run outside half_sdk:
SDK_GUARD=1        # real-robot default (1 when WALKER_C1_REAL=1): enforce
SDK_GUARD=auto     # validate only when a real robot is detected (simulation default)
SDK_GUARD=0        # skip (offline debugging only)
SDK_AUTO_SWITCH=1  # automatically run sdk_mode.sh half_sdk and recheck on failure
Ready / home poses (robot_ready.sh / robot_home.sh)¶
| Command | Purpose |
|---|---|
robot_ready.sh |
Three-stage ready pose: raise shoulder → fold elbow → ready pose (≥5 s each) + open both hands |
robot_ready.sh --dry-run |
Print target poses and stage durations only |
robot_ready.sh --head-pitch 0.5 |
Adjust the head-down angle (default 0.65 rad) |
robot_home.sh |
Three-stage exact reverse to home (all 14 arm joints at 0) |
robot_home.sh --dry-run |
Print targets only |
The ready pose is an absolute target, not a zero position. When standing with arms hanging naturally, the hands are below the table, so the motion must be staged to avoid sweeping the hand across the table edge.
Safety precheck¶
Before deployment, an action-dimension precheck runs: output_features.action.shape[0] must match the robot config action_order dimension, otherwise deployment is refused.
ROBOT_MODELmust match the training DOF (see the table below).- If the policy has no action names, set
ALLOW_DIM_ONLY_POLICY=1(enabled by default). - Hand limits are clipped on both the plugin and bridge sides (plugin
hand_joint_limits→to_bridge_config()→ bridge).
Environment variables (rollout.sh)¶
| Variable | Default | Description |
|---|---|---|
POLICY_PATH |
Required, no default | Checkpoint directory (containing config.json) |
ROBOT_MODEL |
Real: walker_c1_13d / sim: walker_c1_26d |
ROBOT_MODELS key (also --robot.joint_config), switched by WALKER_C1_REAL |
ROBOT_CONFIG |
configs/<ROBOT_MODEL>.json |
Hardware config JSON (selected from ROBOT_MODEL) |
ROBOT_TYPE |
walker_c1 |
Plugin registration name |
WALKER_C1_REAL |
1 |
1 = real robot (13d/task/act_async/guard/real camera); 0 = simulation/offline |
EPISODES |
1 |
Number of episodes; the base strategy does not support multi-episode runs, so values >1 use an outer loop with a reset per episode |
DURATION |
30 |
Maximum seconds per episode |
FPS |
15 |
Control loop FPS (use FPS=30 for 30 fps datasets) |
TASK |
walker c1 pick place |
Task description |
RESET_MODE |
Real: task / sim: sim-scene |
Reset before each episode: sim-scene / task / both / none |
ALLOW_DIM_ONLY_POLICY |
1 |
1 = dimension-only check; 0 = also check action_feature_names |
INFERENCE_TYPE |
Real: act_async / sim: sync |
sync / act_async (chunk → bridge blending at 300 Hz) |
INFERENCE_HZ |
Real: 1 / sim: 2 |
act_async replanning rate |
EXECUTION_HORIZON |
0 |
Truncate act_async chunks after N steps (0 = no truncation) |
PREVIEW_CAMERA |
0 |
1 = also open the preview window |
CAMERA_TOPIC |
Head left when WALKER_C1_REAL=1 |
Camera topic (simulation overrides to /sensor/camera/head/color/raw) |
CAMERA_MSG_TYPE |
shm_msgs/Image6m when WALKER_C1_REAL=1 |
Camera message type (simulation: sensor_msgs/Image) |
SDK_GUARD |
Real: 1 / sim: auto |
half_sdk guard |
SDK_AUTO_SWITCH |
0 |
1 = automatically switch to half_sdk when the guard fails |
WALKER_C1_SINGLE_ACTION_SMOOTH_S |
0.15 |
Smoothing window (seconds) for a single sync action; 0 disables; only affects sync |
ZMQ_HOST |
127.0.0.1 |
Bridge address (use the robot-side IP for cross-machine deployment) |
Robot configuration (ROBOT_MODELS registry)¶
| Registry key | Dimension | End effector | Config file |
|---|---|---|---|
walker_c1_13d |
13D (right arm 7 + right hand 6) | Right dexterous hand (13D variant; left hand held at home via inactive_fill) | configs/walker_c1_13d.json |
walker_c1_26d |
26D (left arm 7 + right arm 7 + left hand 6 + right hand 6) | Both dexterous hands | configs/walker_c1_26d.json |
In the 13D config,
action_ordercontains only the right arm and right hand;body.groupsstill keepsleft_arm, andinactive_fillfills the left arm 7 + left hand 6 with home values and sends them (hold position on hardware, home in simulation).
Online evaluation (recording inference trajectories)¶
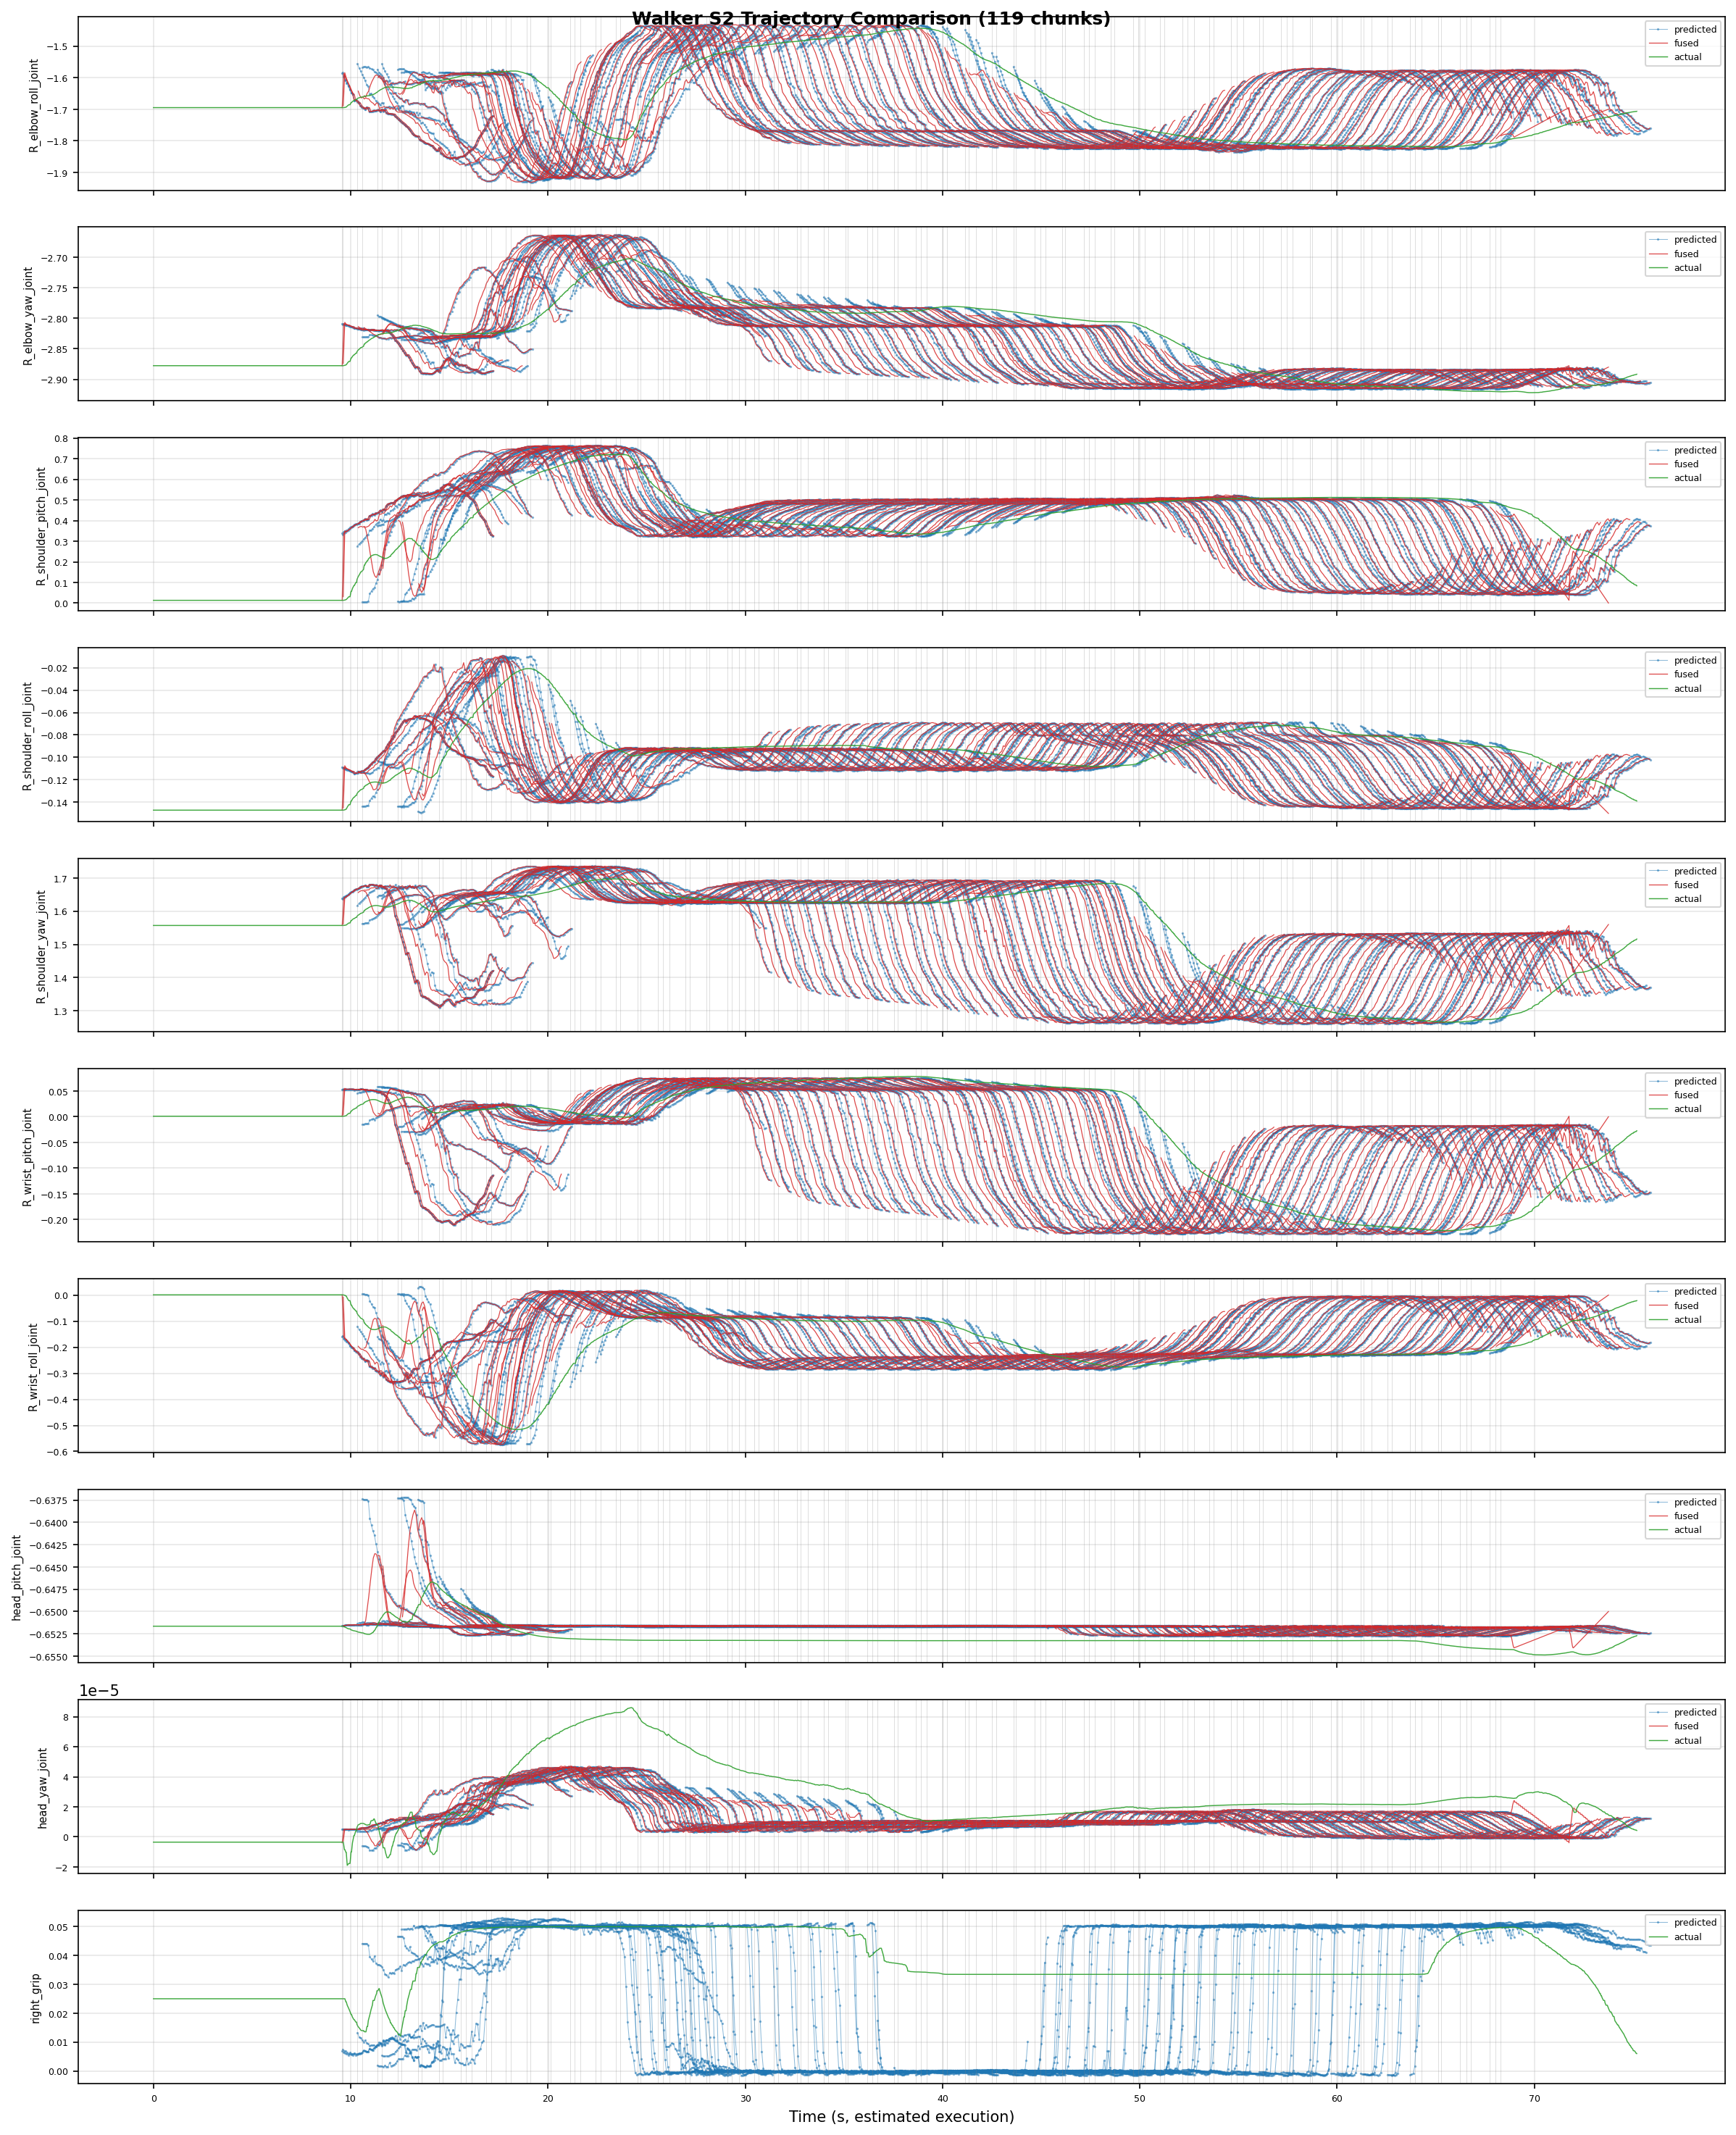
Set RECORD_ACTIONS=1 (and RECORD_OUTPUT_DIR) during deployment to record rollout actions for analyzing model predictions, robot execution, and ACT blending. Records are saved under ubt_IL/scripts/deploy/output by default.
Offline policy evaluation¶
Run the offline MSE evaluation (ubt_IL/scripts/eval/eval_policy.py) before deployment; see Imitation Learning Platform §5.
Inference server (warm start)¶
For long-running or multi-task deployment, use the inference server to avoid a cold start each time (rollout.sh must load the policy and start the bridge on every run). It supports launch/load/start/stop/home/status/watch/shutdown; see Inference server.
start/home/shutdownmove the robot; keep the operator next to it.
FAQ¶
| Symptom | Fix |
|---|---|
| Robot does not move | Does preview_camera.py --once produce an image? Is ROS_DOMAIN_ID / RMW consistent with the robot? Check the ros2_walker_c1_bridge log |
| Only part of the arm moves | Policy dimension and action_order mismatch (the precheck exits), or the left hand is all zeros throughout the data (the task only uses the right hand; normal) |
| Motion jitter | Increase FPS and --inference-hz, or switch to act_async chunk blending |
| Camera timeout | Verify topic name and message type; QoS must be BEST_EFFORT; real shm_msgs/Image6m must be specified explicitly |
reset.py reports No module named rclpy |
Use reset.sh (runs /usr/bin/python3), not the venv python3 |
| Port already in use | ss -lntp \| grep 566; do not run two bridges on the same host |
| Arm does not return after exit | disable_torque_on_disconnect was set false, or the bridge was killed externally |
sdk_mode.sh reports legs are not standing |
Switch to standing with the remote/Web UI, or let the script run A000004 (enabled by default) |
developModeState=sdk_error |
Press the emergency stop → exit developer mode or restart motion control, then run half_sdk again |