Walker TienKung Pro
Walker TienKung Pro is a humanoid robot with 50 DOF and two 12-DOF five-finger dexterous hands.
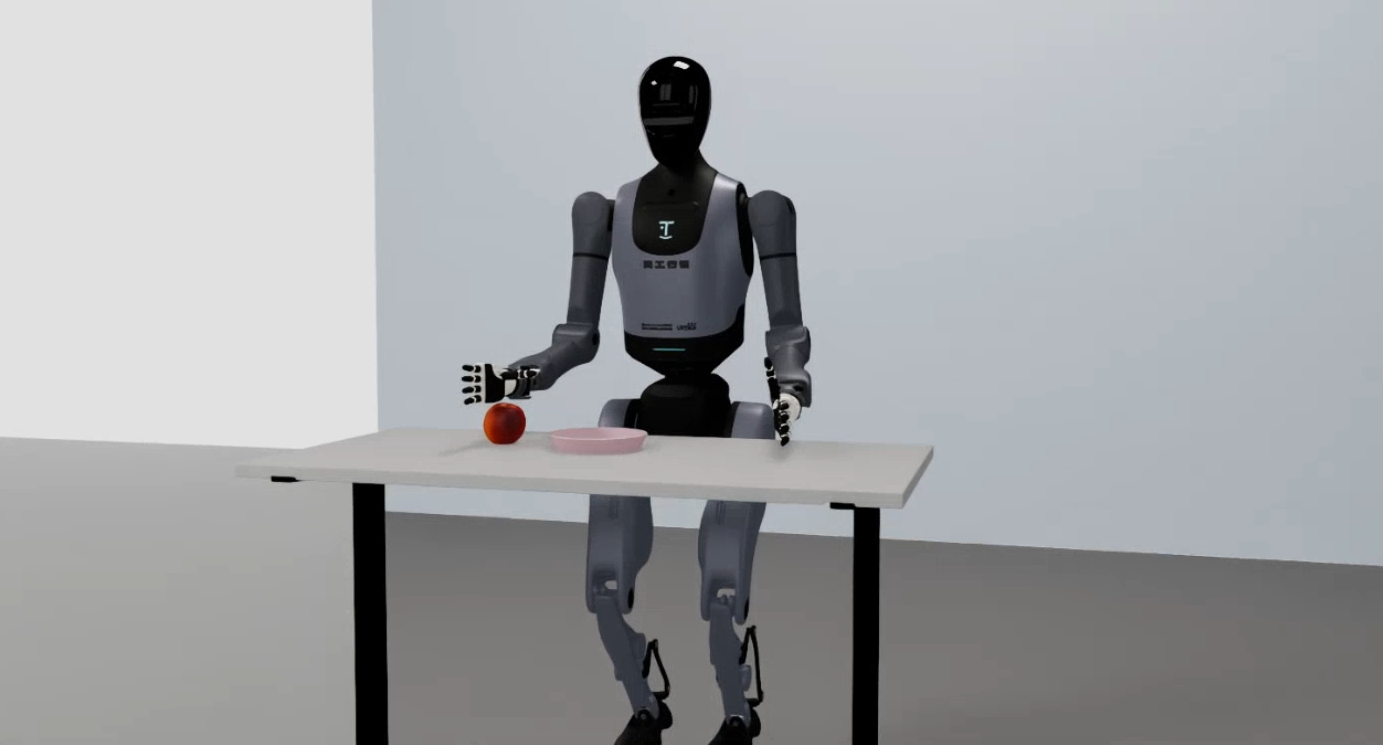
Specifications
| Item | Specification |
|---|---|
| DOF | 50 |
| End effectors | 2 × 12-DOF five-finger dexterous hands |
| Common training dimensions | 26D (both arms 7+7 + both hands 6+6) / 13D (right arm 7 + right hand 6, single arm) |
| LeRobot plugin | ubt_IL/tienkung/lerobot_robot_tienkung |
| USD model | ubt_sim/assets/robots/tienkung_pro/tienkung_pro_v2.usd |
| State/action order (26D) | [left arm 7 | right arm 7 | left hand 6 | right hand 6] |
In single-arm data (for example, right-hand-only collection), the locked dimensions are constant, which breaks normalization during training (QUANTILES NaN/Inf). Convert such data with the 13D config to drop the dead dimensions.
Simulation task
| Task ID | Scene | Description |
|---|---|---|
UBTSim-TienkungPro-Parlor-v0 |
Parlor | Apple-picking teleoperation + data collection (default) |
Documentation
Platform entry points (shared architecture and commands are on the platform overview pages):
- Simulation Platform · Walker TienKung Pro - Container build, launching simulation, batch HDF5 collection, camera test, data preview (platform overview)
- Imitation Learning Platform · Walker TienKung Pro - HDF5 -> LeRobot conversion, ACT training, offline evaluation (platform overview)
In order of use:
- Simulation workflow - End to end: simulation collection -> conversion -> training -> evaluation -> sim deployment
- Real-robot workflow - End to end: real collection -> conversion -> training -> evaluation -> real deployment
- ARM board deployment - Docker-free deployment on Jetson AGX Orin (dual Python stack)
Deployment results
Simulation
Real robot